Lab 1: Isaac Sim Basic Usage and First Physics Simulation
Published:
Published:
Instructor: Prof. Sangram Redkar
Published:
Status: This laboratory is under preparation. Complete all energized wiring and controller work only with instructor approval and the equipment-specific wiring diagram in front of you.
Published:
Status: This laboratory is under preparation. The final controller project and acceptance tests will be published before release.
Published:
Status: This laboratory is under preparation. Final workstation assignments and pneumatic schematics will be added before release.
Published:
Status: This laboratory is under preparation. The final Ignition gateway and tag-provider instructions will be added before release.
Published:
Status: This laboratory is under preparation. Robot-specific safety and programming instructions will be finalized for each workstation.
Published:
Status: This laboratory is under preparation. The final data architecture and dashboard requirements will be published before release.
Aug 2021 – Dec 2021
Combined MATLAB kinematics with Bluetooth-based servo control to position a robotic arm and record repeatable motion sequences.
Aug 2021 – Dec 2021
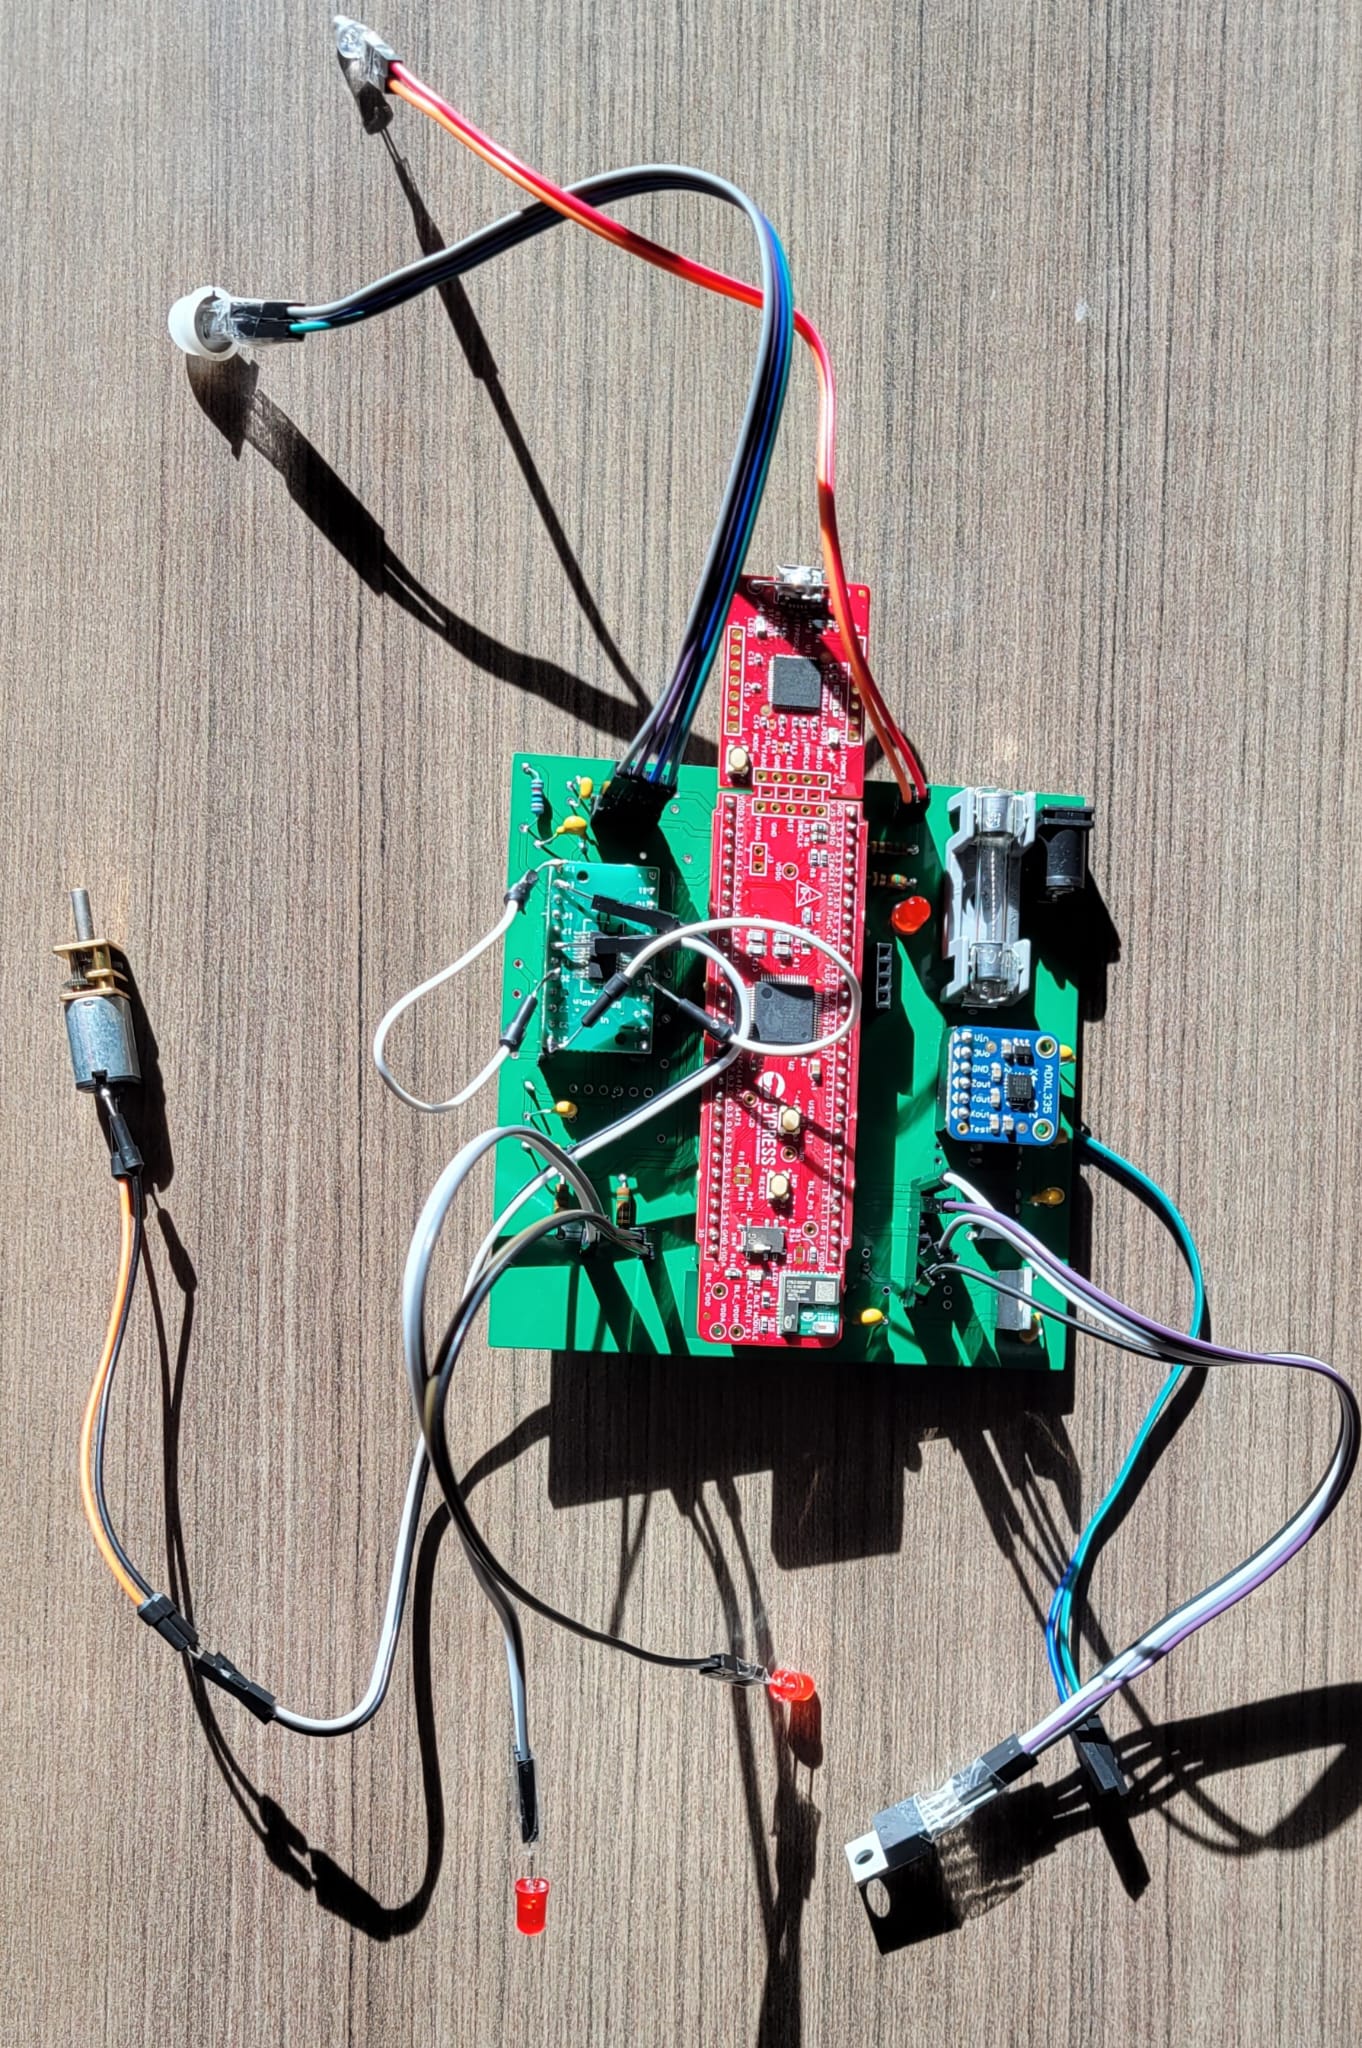
Designed and built a dual-mode holiday animatronic around a custom PSoC-based PCB, motion sensing, motor control, LEDs, and Bluetooth communication.
Jan 2022 - Apr 2022
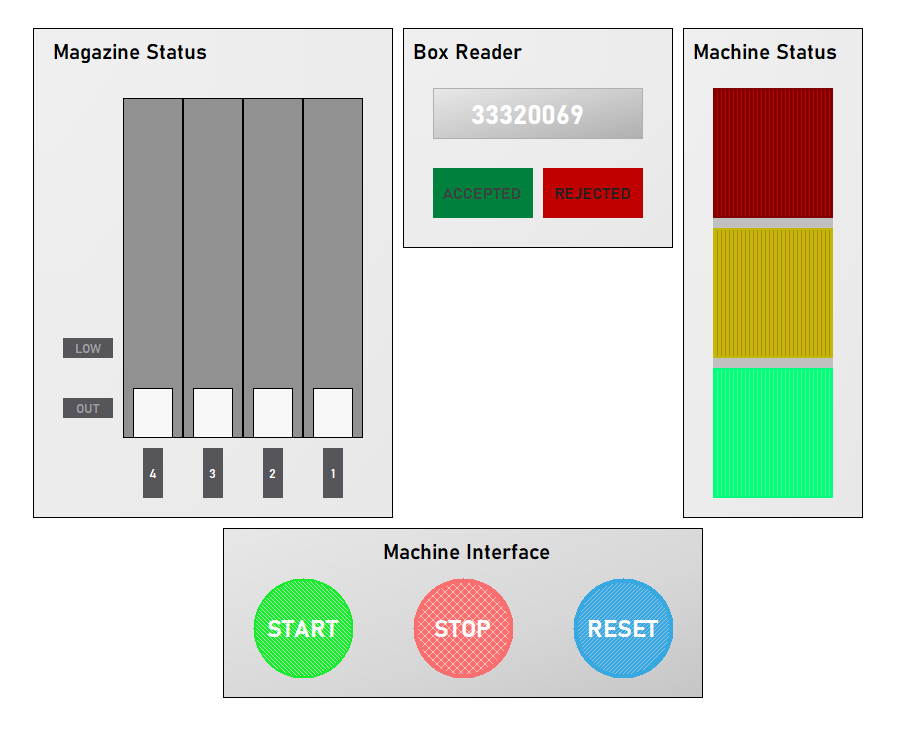
Automated an SMC HAS-200 workstation with Rockwell ladder logic, barcode-based sorting, pneumatic handling, and SCADA/HMI controls.
Jan 2022 - Apr 2022
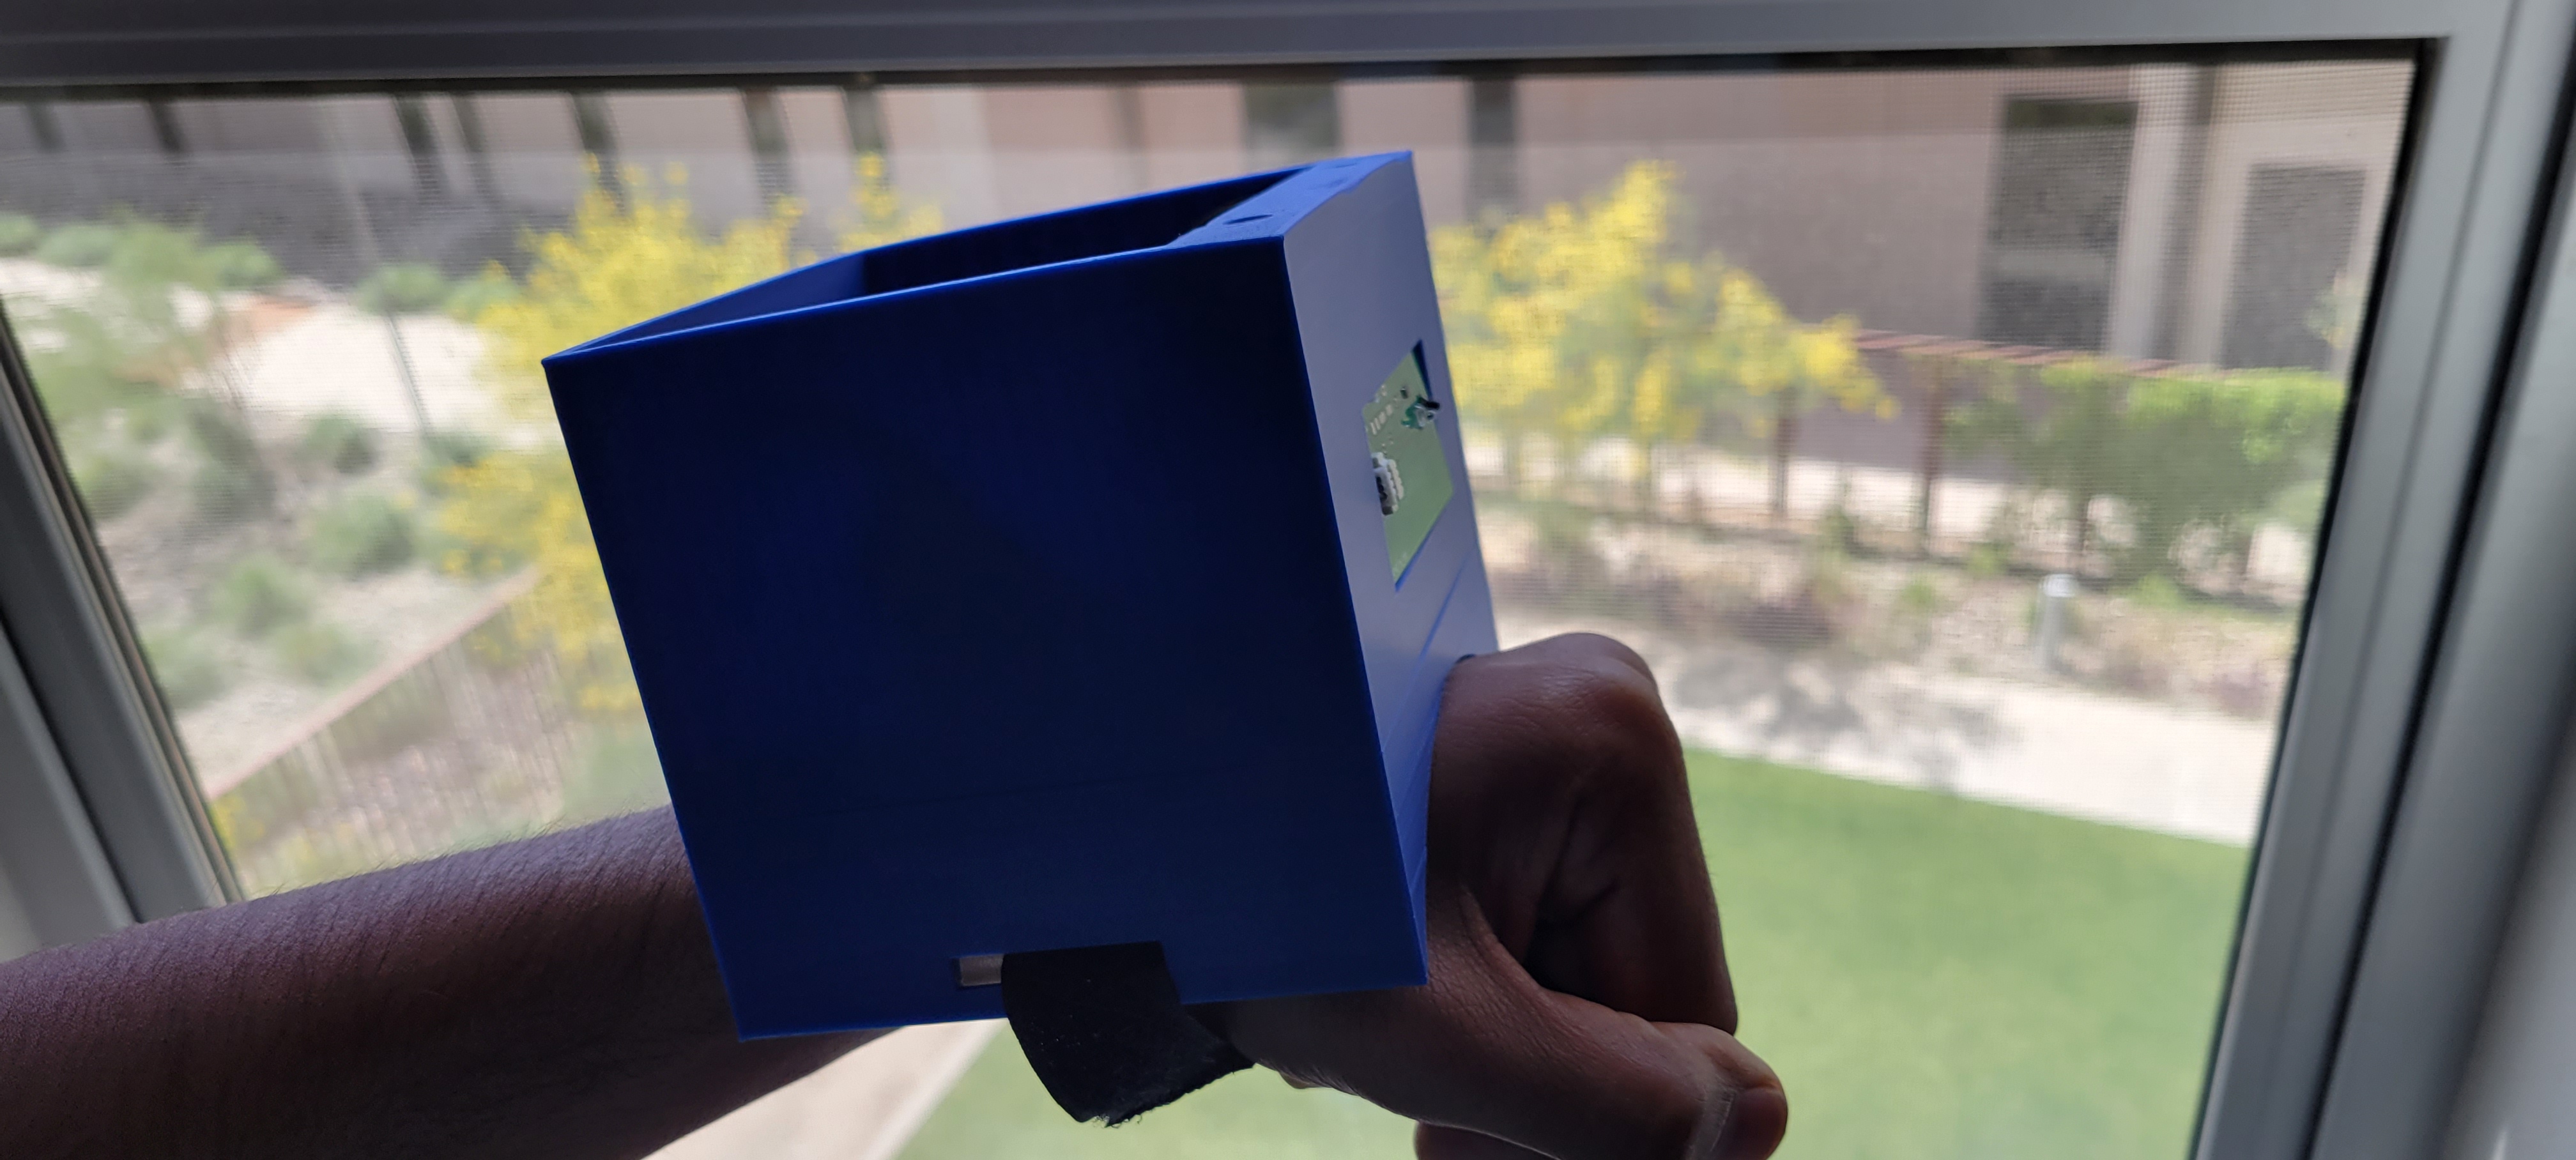
Developed a wearable embedded prototype that measures object distance and presents it on a compact display for users with impaired depth perception after stroke.
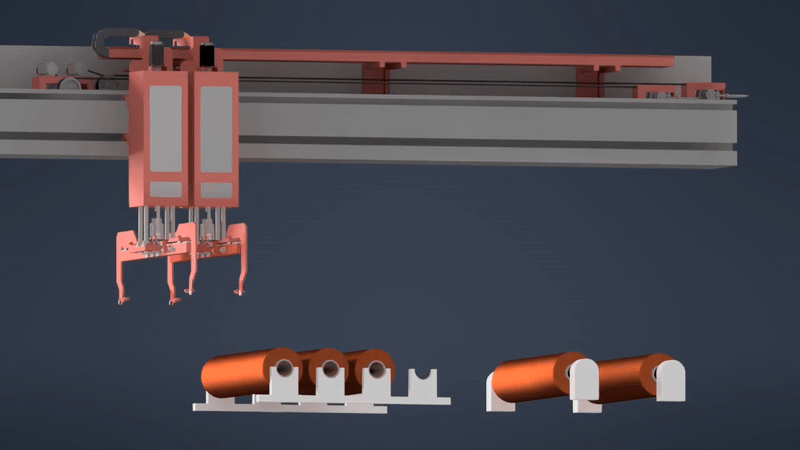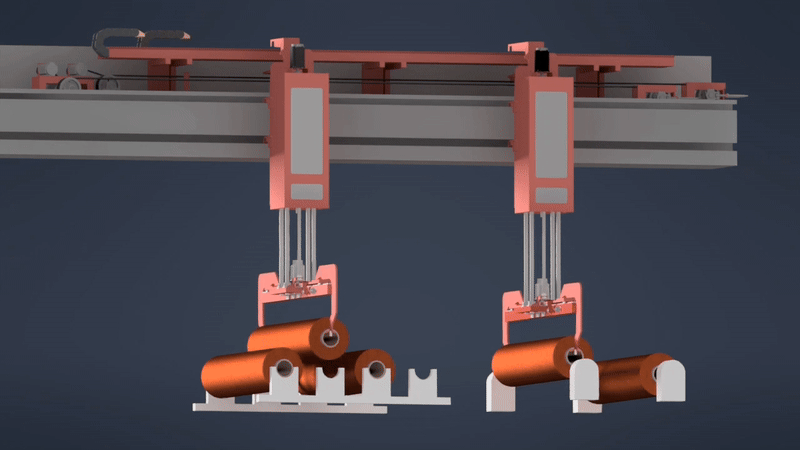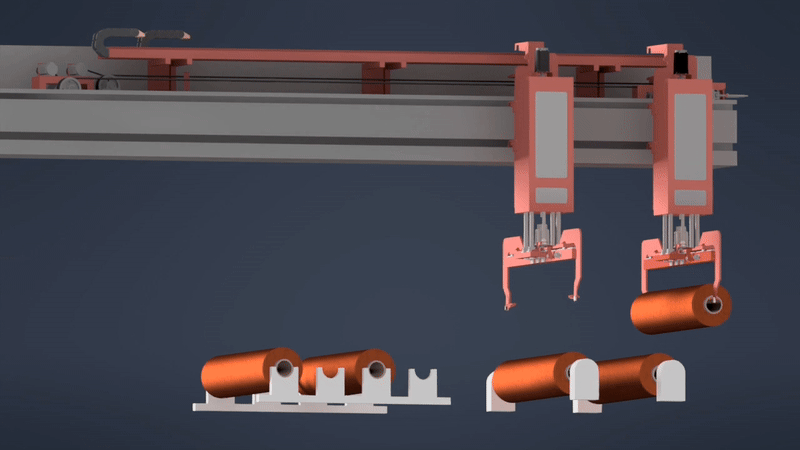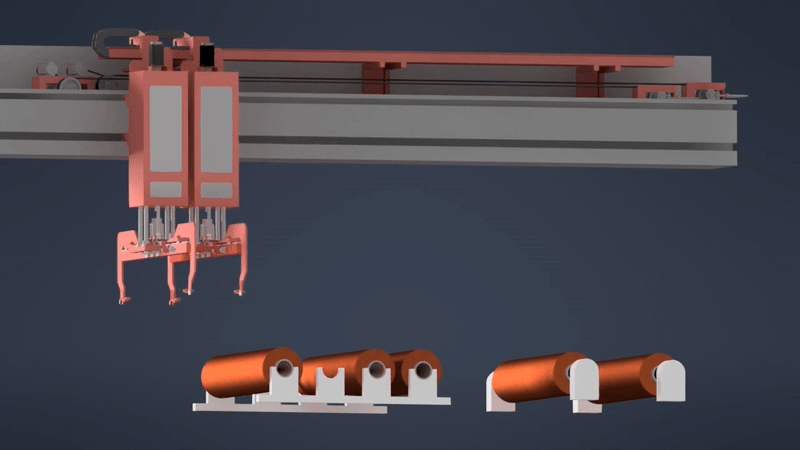
Aug 2022 – Apr 2023
Designed a twin-hoist concept for Isola’s PCB-laminate line that reduced the modeled worst-case roll-changeover time from two minutes to 36 seconds.
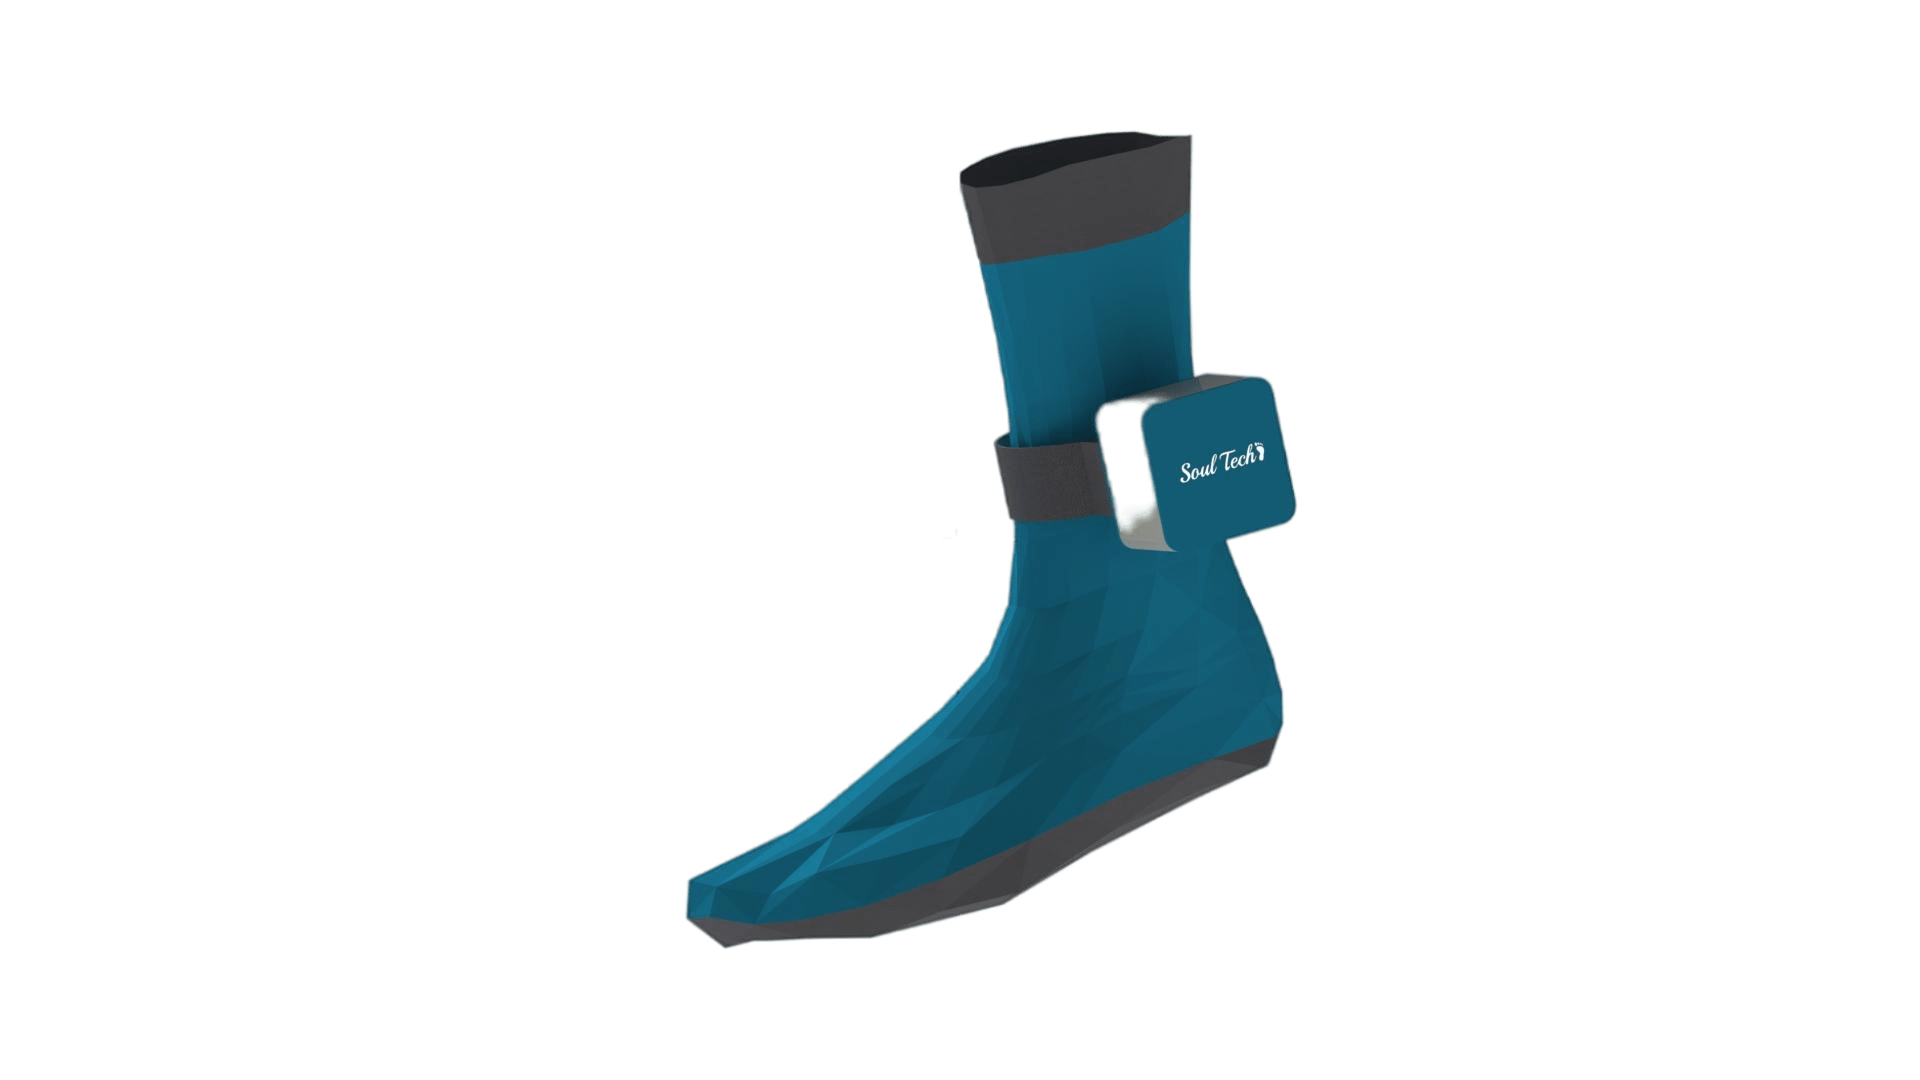
Jan 2023 – May 2023
Developed pressure-sensing footwear with inertial measurement, Bluetooth telemetry, and haptic feedback for portable gait assessment.
Jan 2024 – Apr 2024
Designed a portable metabolic-monitor prototype with custom packaging, embedded data acquisition, BLE communication, and a MATLAB interface.
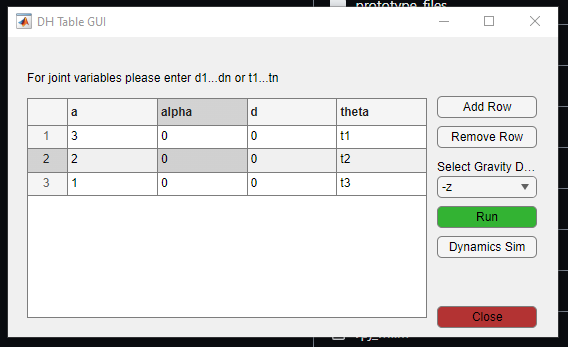
Apr 2024
Developed a MATLAB robotics package for user-defined manipulators, dynamics simulation, compliance control, impedance control, and interactive analysis.
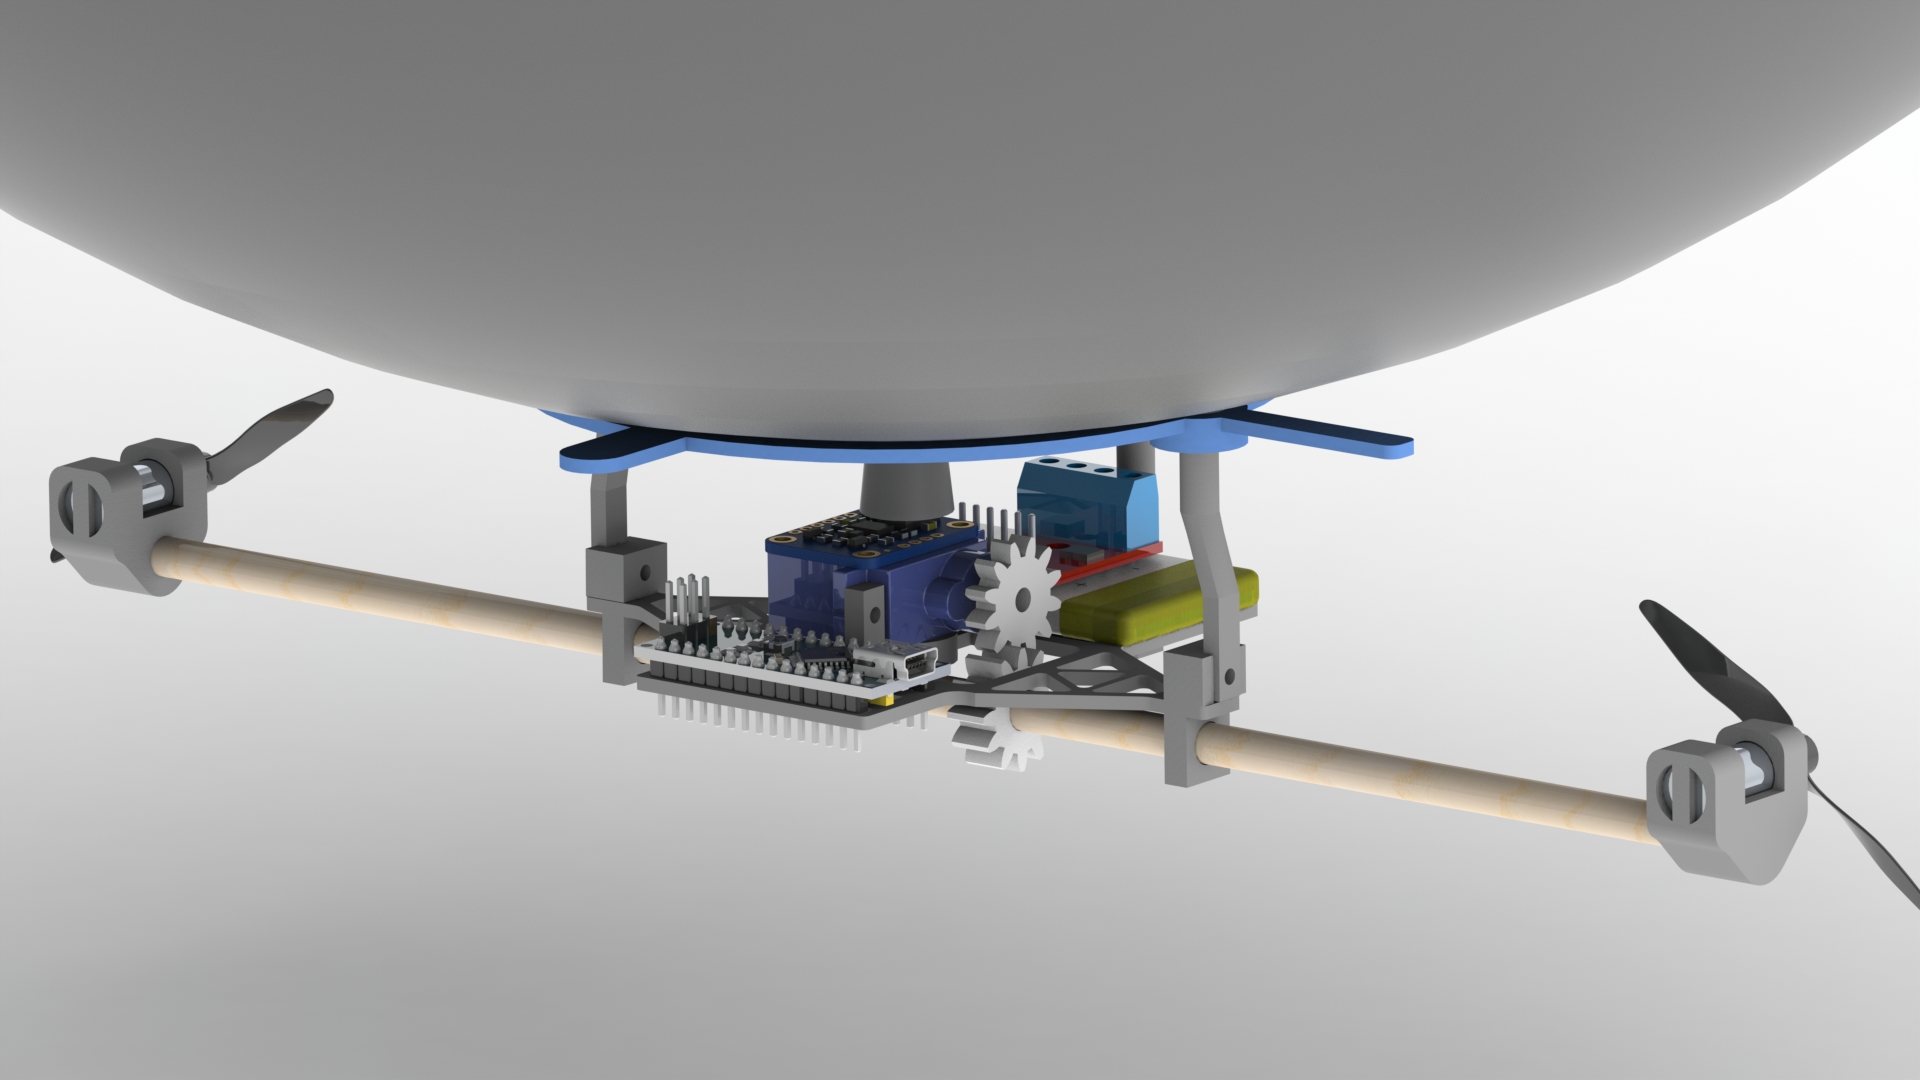
Spring 2025
Built a modular ROS 2 platform that combines vision, inertial sensing, altitude estimation, control allocation, and browser-based telemetry for an autonomous indoor BLIMP.
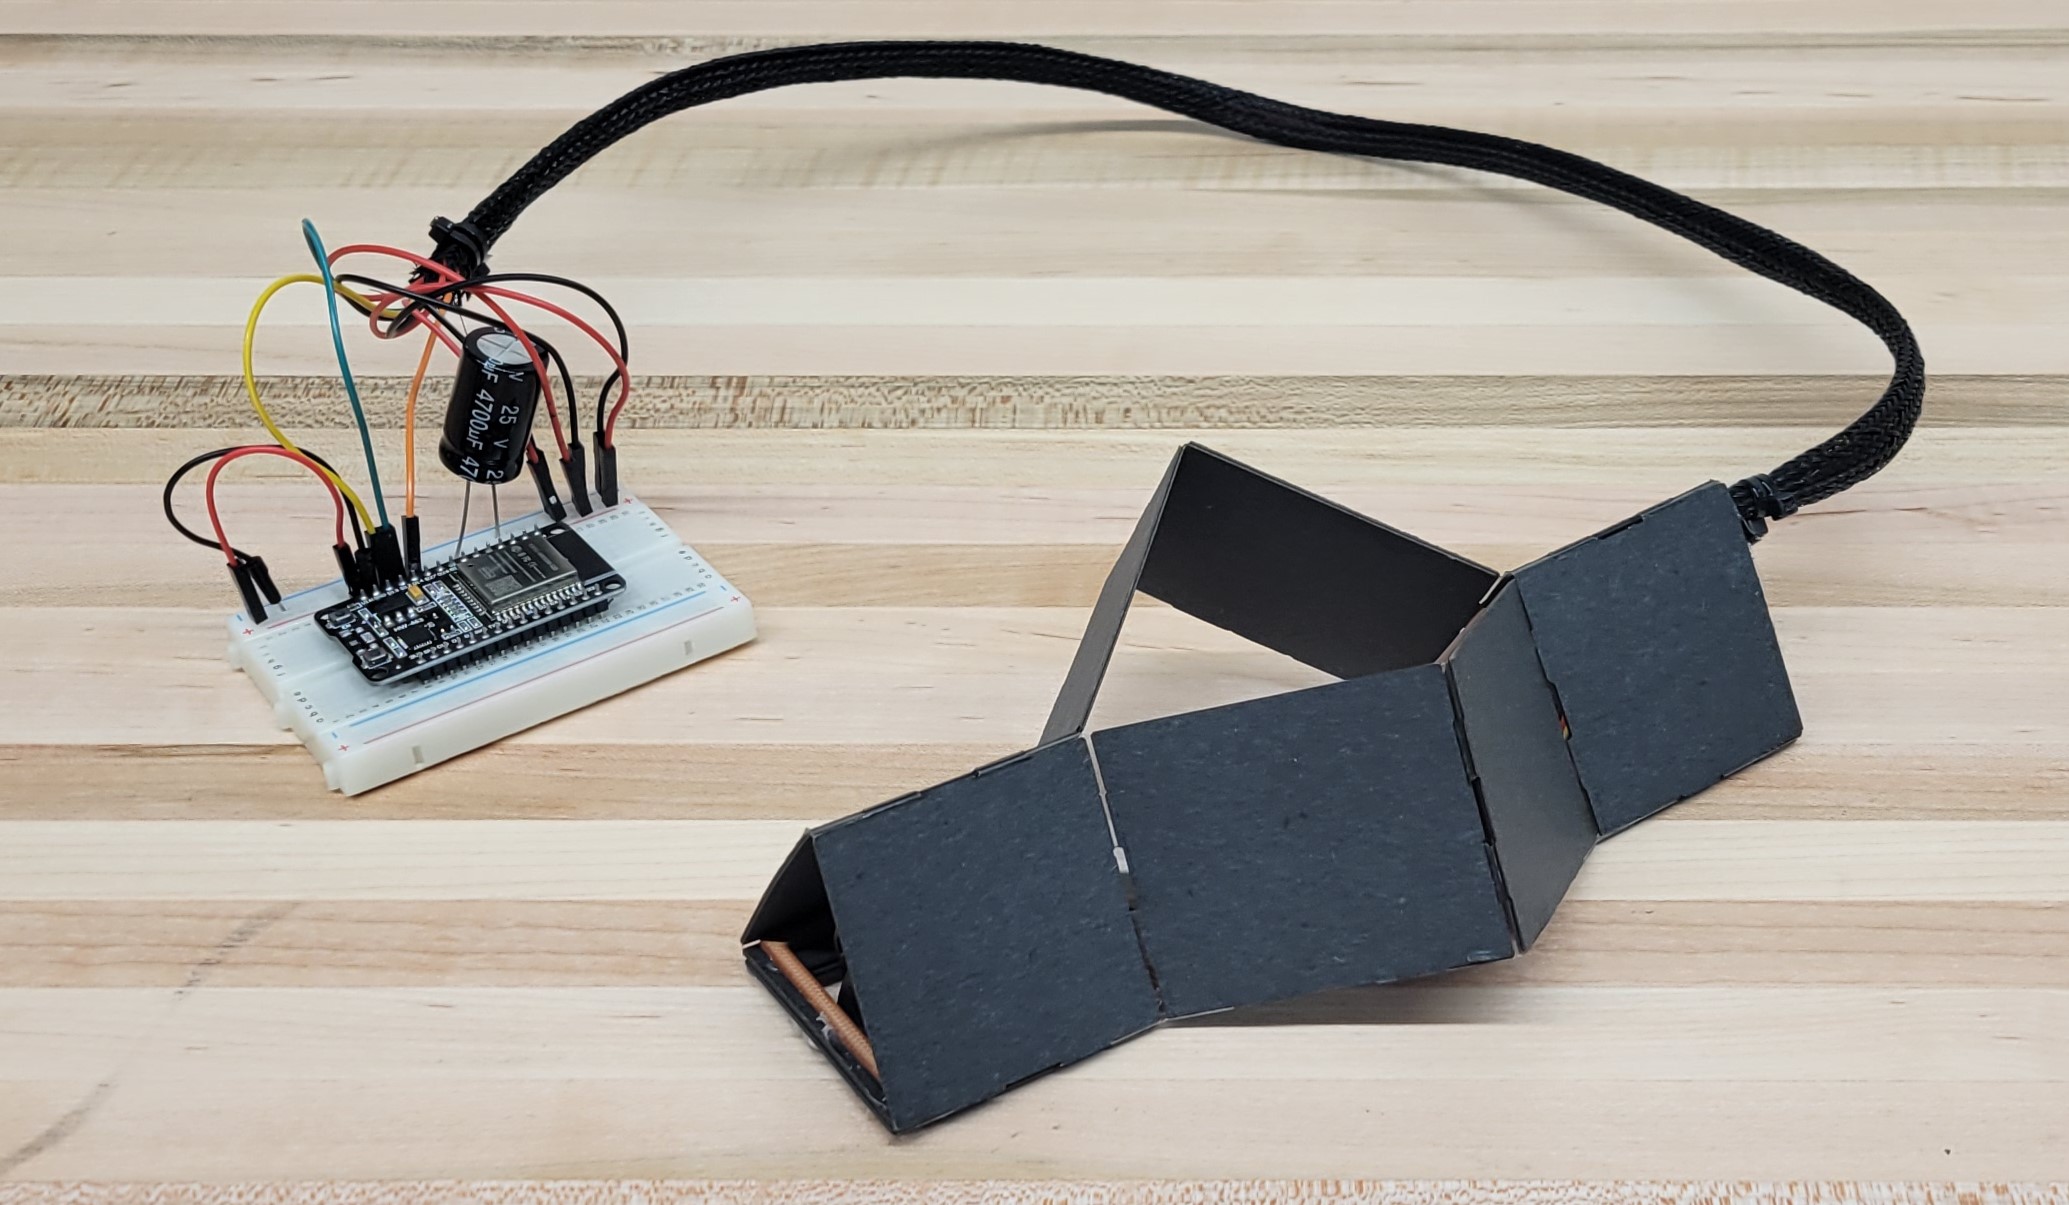
Oct 2025 – Dec 2025
Designed, simulated, fabricated, and tested a laminate inchworm robot whose gait combines a foldable linkage, alternating friction anchors, and ESP32-controlled actuation.
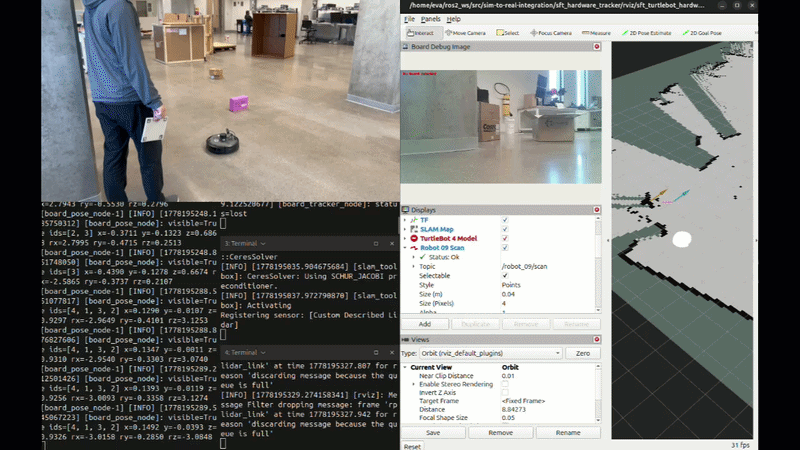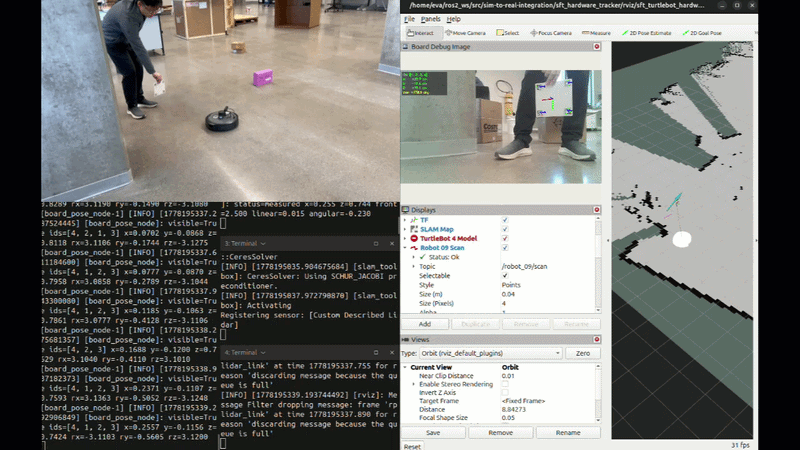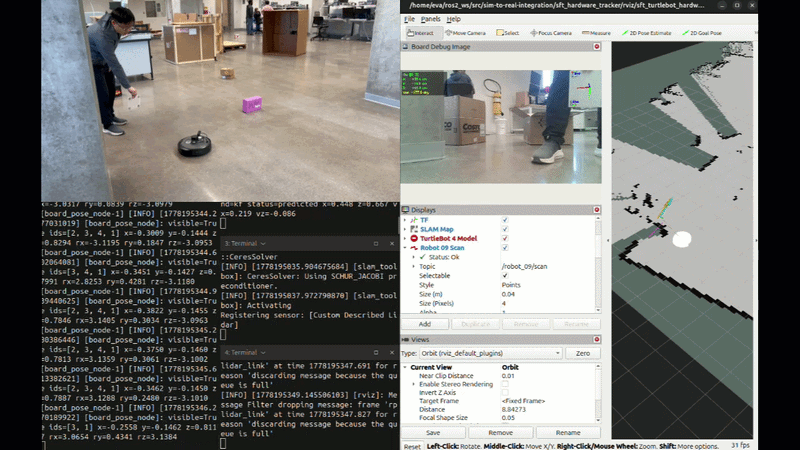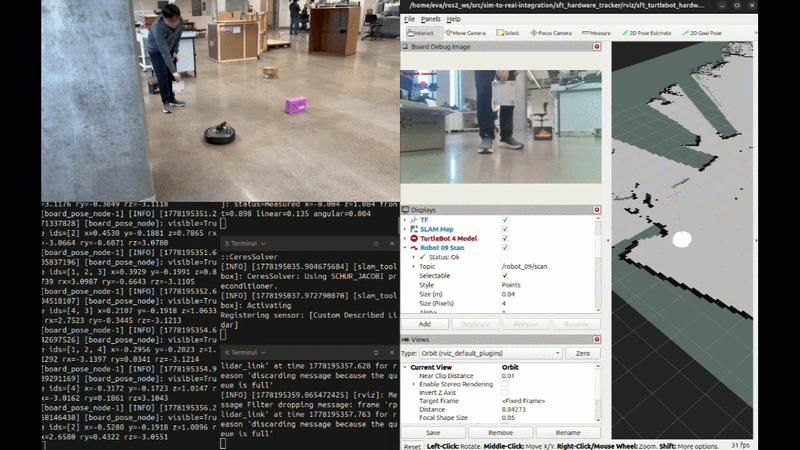
2026
Developed an autonomous TurtleBot 4 system that follows an ArUco-tagged target, predicts through short occlusions, enforces LiDAR safety, and records a 2D reconstruction.
Sep 2026 – Present
Developing a dual-UR5e industrial automation demonstrator for Stellantis Factory Booster Day 2026 in collaboration with ASU and Wandelbots.
Published in Journal 1, 2009
This paper is about the number 1. The number 2 is left for future work.
Recommended citation: Your Name, You. (2009). "Paper Title Number 1." Journal 1. 1(1).
Download Paper | Download Slides | Download Bibtex
Published in Journal 1, 2010
This paper is about the number 2. The number 3 is left for future work.
Recommended citation: Your Name, You. (2010). "Paper Title Number 2." Journal 1. 1(2).
Download Paper | Download Slides
Published in Journal 1, 2015
This paper is about the number 3. The number 4 is left for future work.
Recommended citation: Your Name, You. (2015). "Paper Title Number 3." Journal 1. 1(3).
Download Paper | Download Slides
Published in GitHub Journal of Bugs, 2024
This paper is about fixing template issue #693.
Recommended citation: Your Name, You. (2024). "Paper Title Number 3." GitHub Journal of Bugs. 1(3).
Download Paper
Teaching Assistant Graduate/Undergraduate course, Arizona State University, 2023
Served as a Teaching Assistant for Robotic Systems II during the Spring 2023, Spring 2024, and Spring 2026 semesters.
Grader Undergraduate course, Arizona State University, 2023
Served as a Grader for Thermo-Fluids I during the Summer 2023 semester.
Teaching Assistant Graduate/Undergraduate course, Arizona State University, 2023
Served as a Teaching Assistant for Robotics Systems I during the Fall 2023 and Fall 2025 semesters. Previously completed the course as a graduate student.
Teaching Assistant Graduate course, Arizona State University, 2024
Served as a Teaching Assistant for Applied Linear Algebra during the Spring 2024 semester.
Teaching Assistant Graduate course, Arizona State University, 2024
Served as a Teaching Assistant for Python during the Spring 2024 semester.
Teaching Assistant Graduate course, Arizona State University, 2026
Served as a Teaching Assistant for RAS 598: Industrial Robotics & Smart Factory Automation during the Spring 2026 and Summer 2026 semester.