Stellantis Industrial Physical AI Robot Demonstrator
Sep 2026 – Present
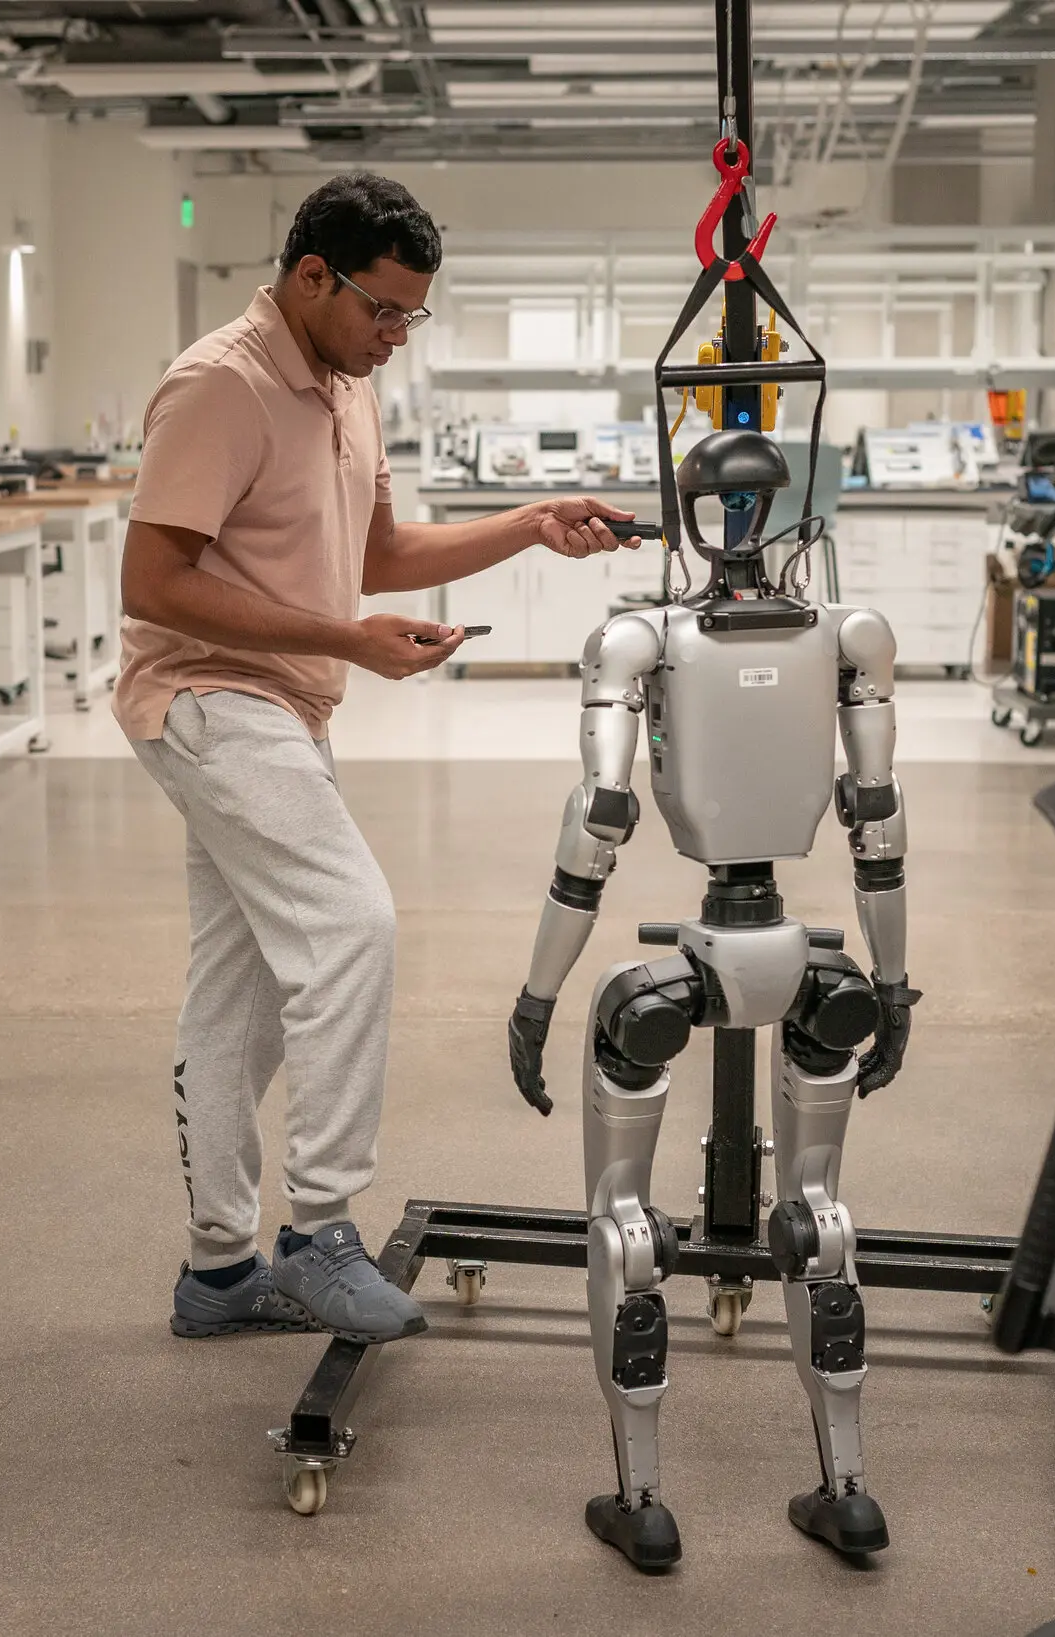
Developing a dual-UR5e industrial automation demonstrator for Stellantis Factory Booster Day 2026 in collaboration with ASU and Wandelbots.
Sep 2026 – Present
Developing a dual-UR5e industrial automation demonstrator for Stellantis Factory Booster Day 2026 in collaboration with ASU and Wandelbots.
2026
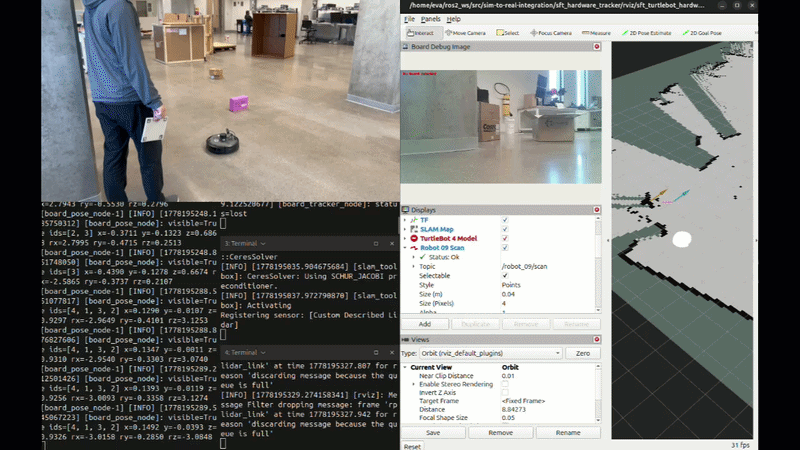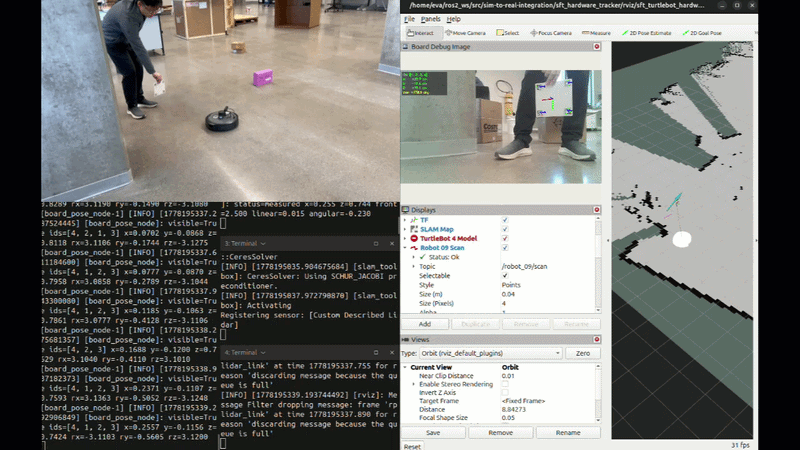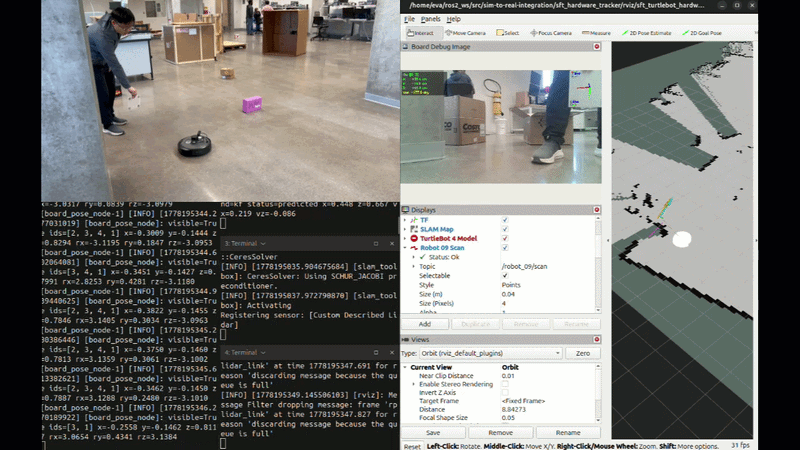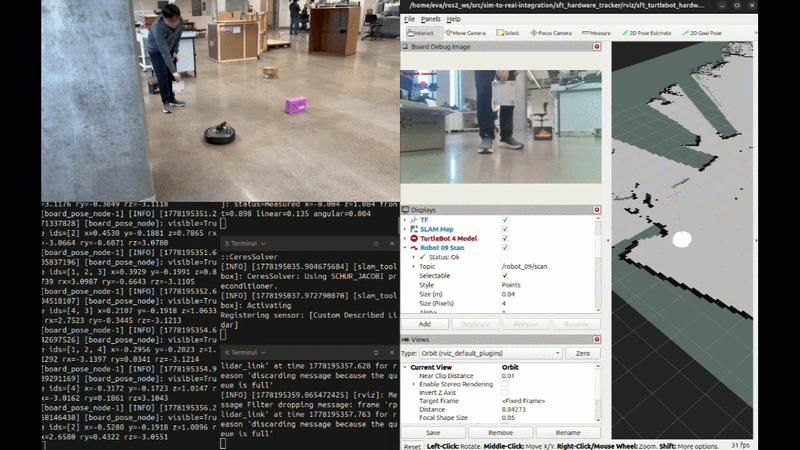
Developed an autonomous TurtleBot 4 system that follows an ArUco-tagged target, predicts through short occlusions, enforces LiDAR safety, and records a 2D reconstruction.
Oct 2025 – Dec 2025
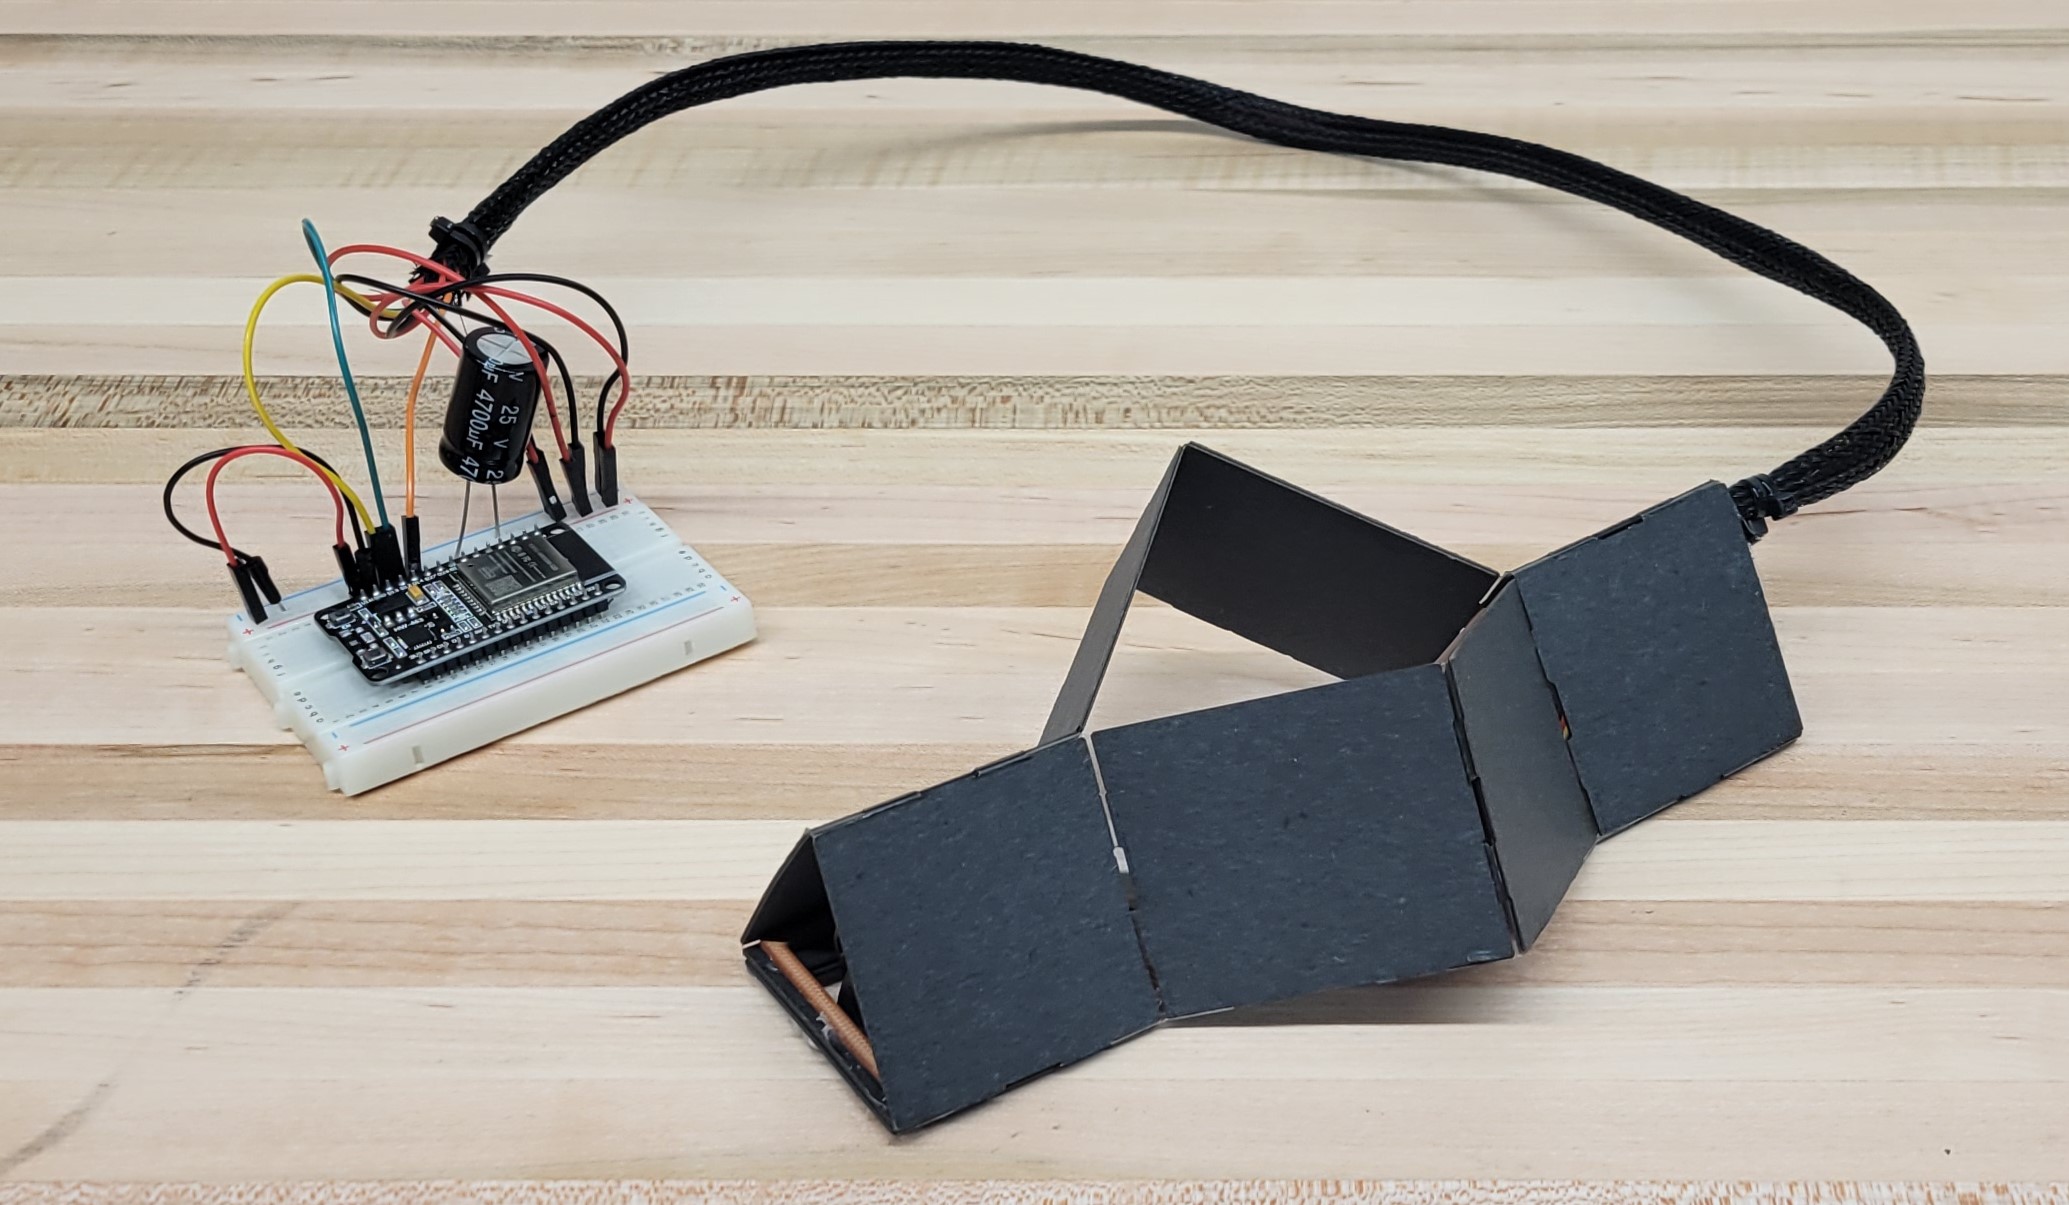
Designed, simulated, fabricated, and tested a laminate inchworm robot whose gait combines a foldable linkage, alternating friction anchors, and ESP32-controlled actuation.
Spring 2025
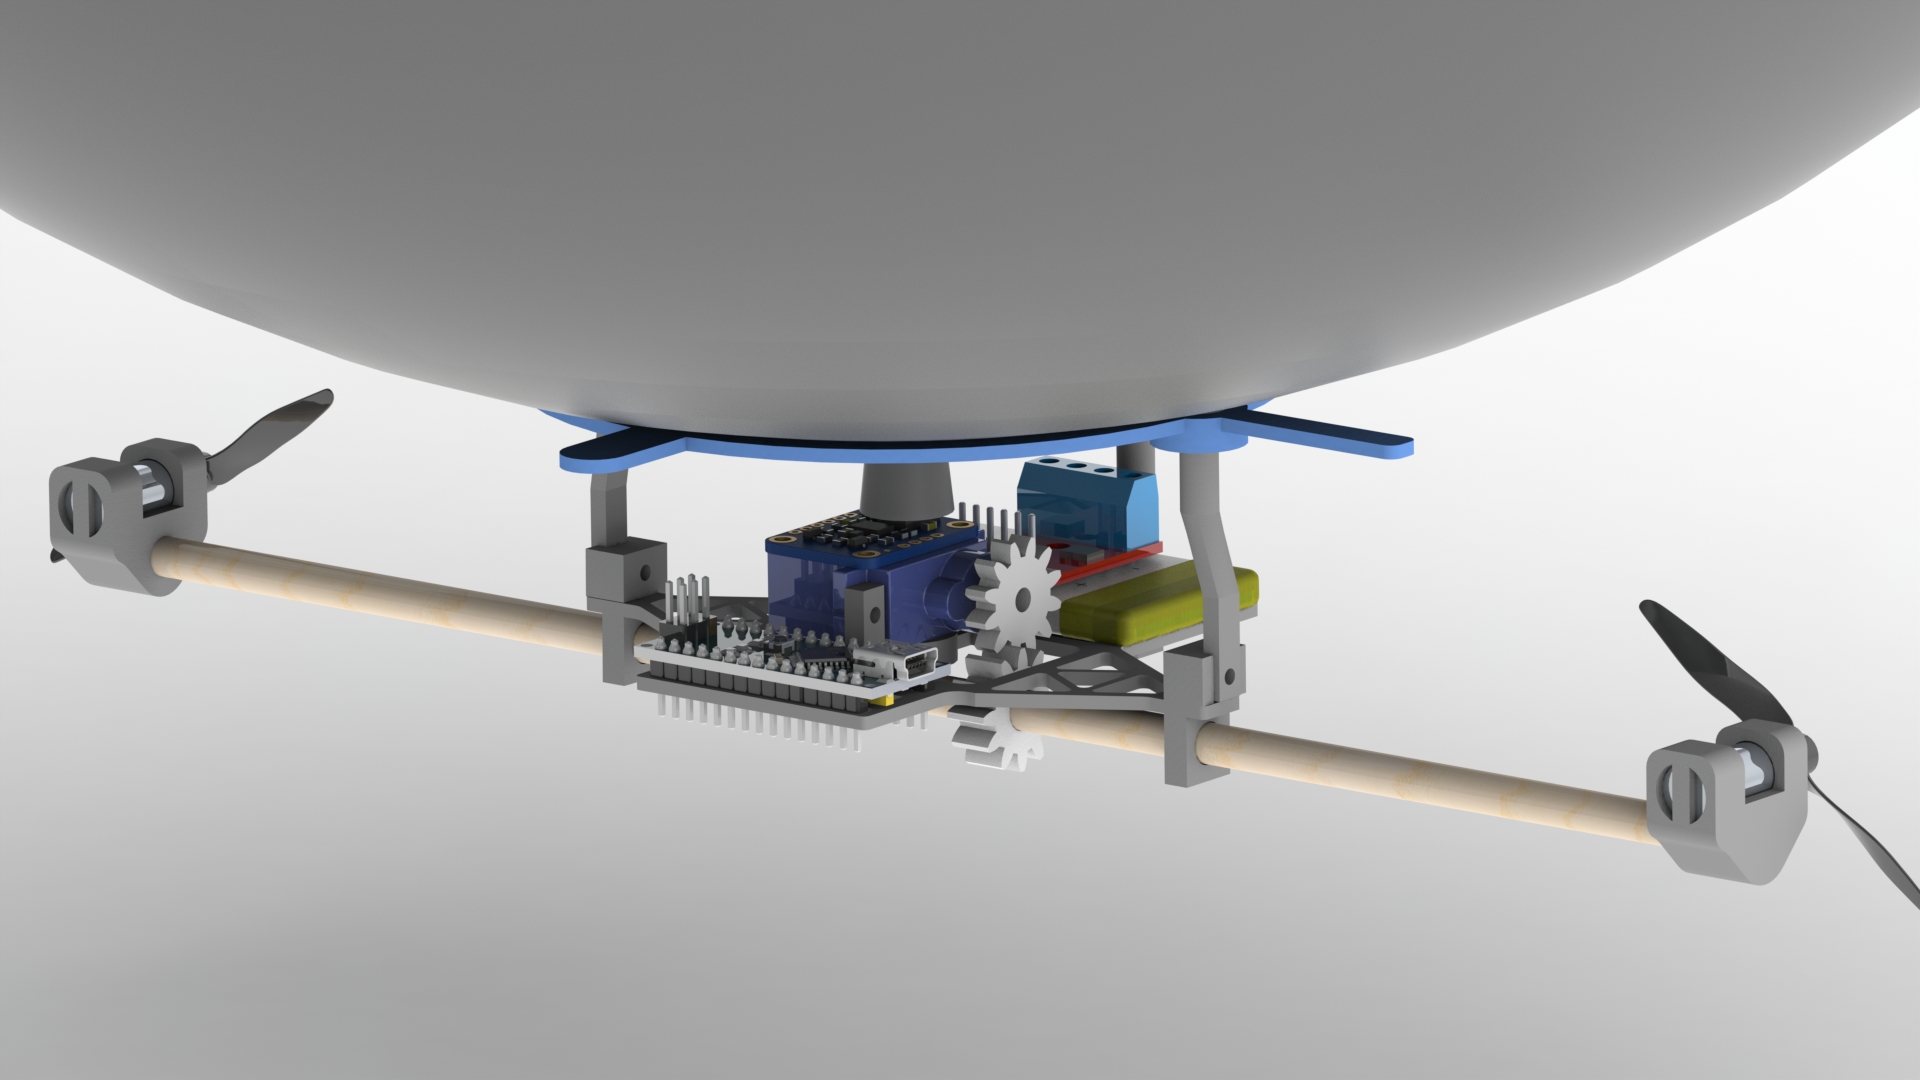
Built a modular ROS 2 platform that combines vision, inertial sensing, altitude estimation, control allocation, and browser-based telemetry for an autonomous indoor BLIMP.
Apr 2024
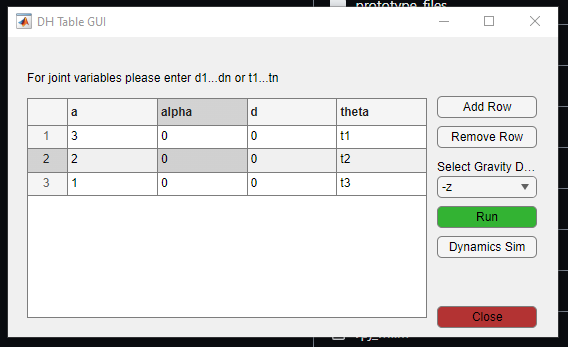
Developed a MATLAB robotics package for user-defined manipulators, dynamics simulation, compliance control, impedance control, and interactive analysis.
Jan 2024 – Apr 2024
Designed a portable metabolic-monitor prototype with custom packaging, embedded data acquisition, BLE communication, and a MATLAB interface.
Jan 2023 – May 2023
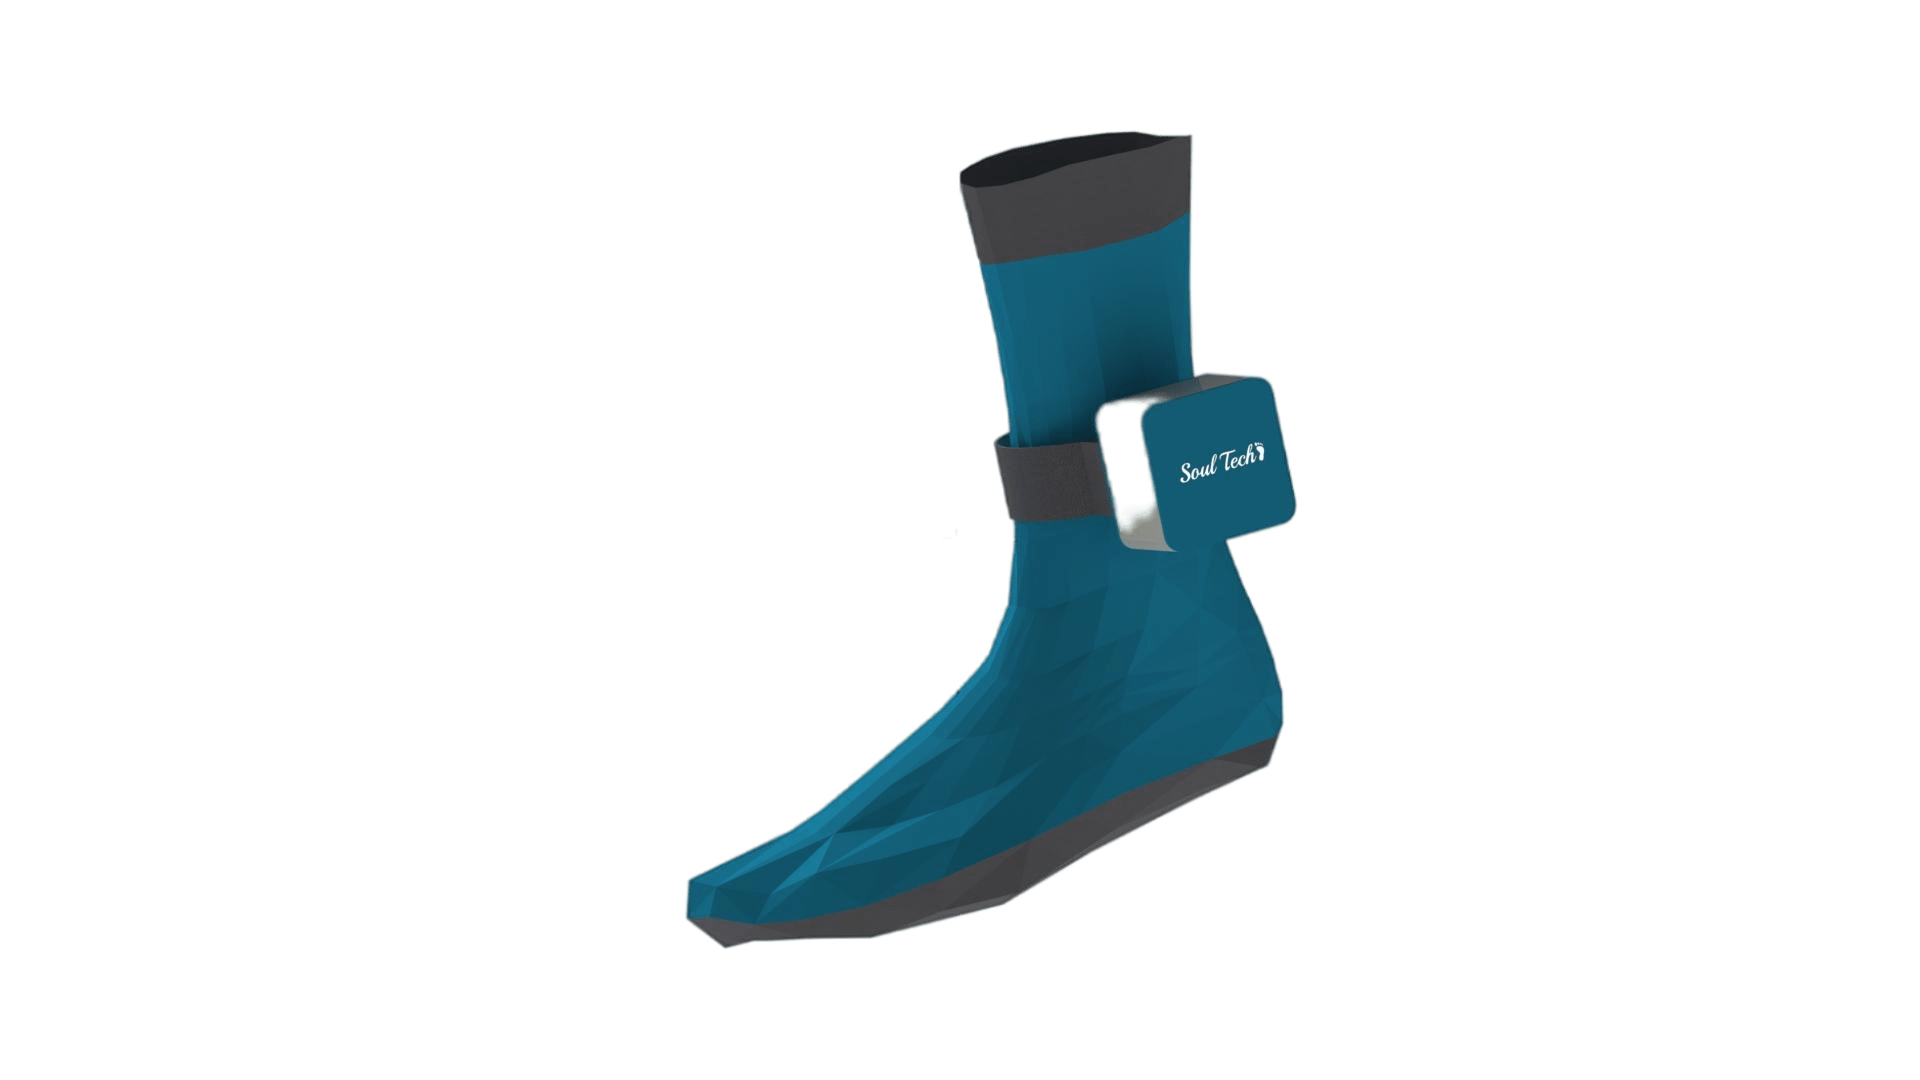
Developed pressure-sensing footwear with inertial measurement, Bluetooth telemetry, and haptic feedback for portable gait assessment.
Aug 2022 – Apr 2023
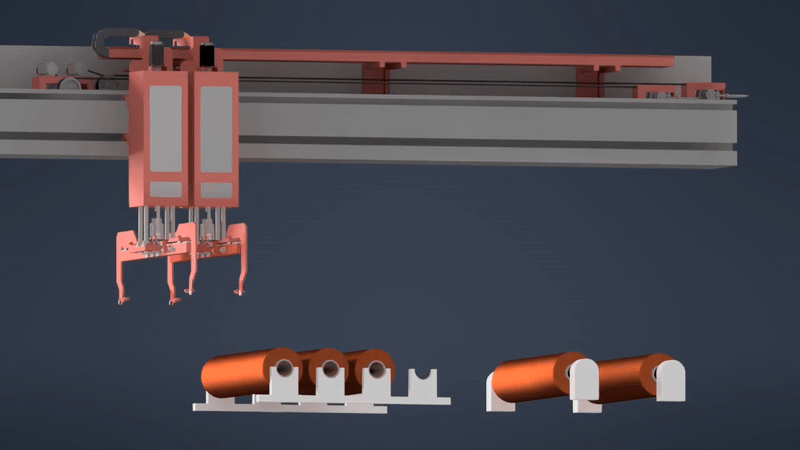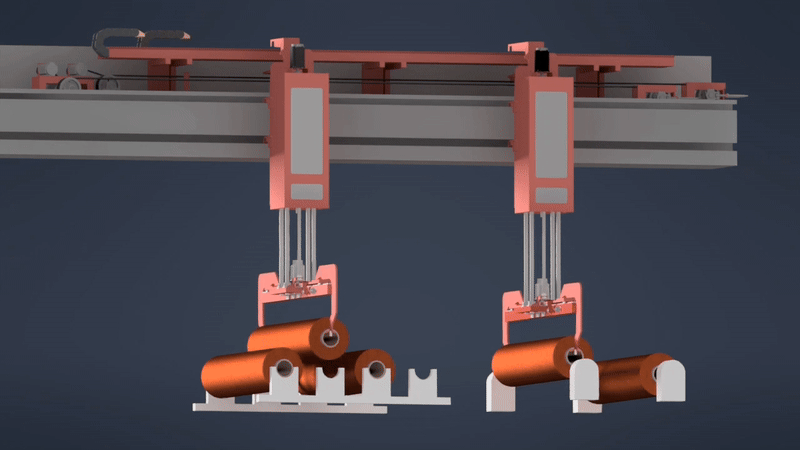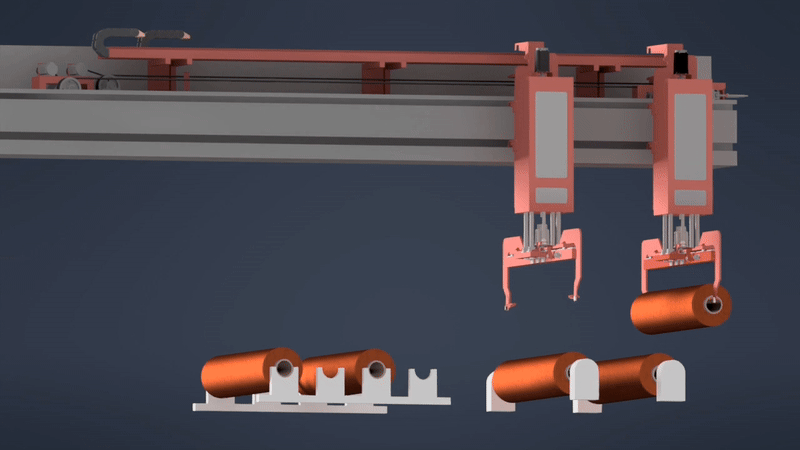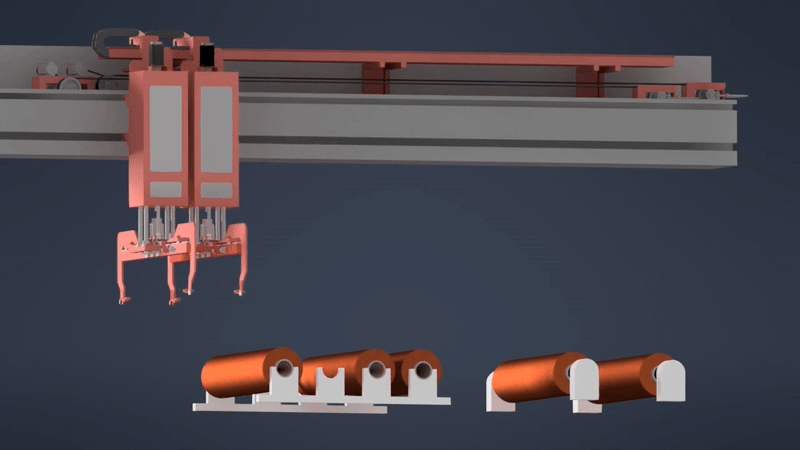
Designed a twin-hoist concept for Isola’s PCB-laminate line that reduced the modeled worst-case roll-changeover time from two minutes to 36 seconds.
Jan 2022 - Apr 2022
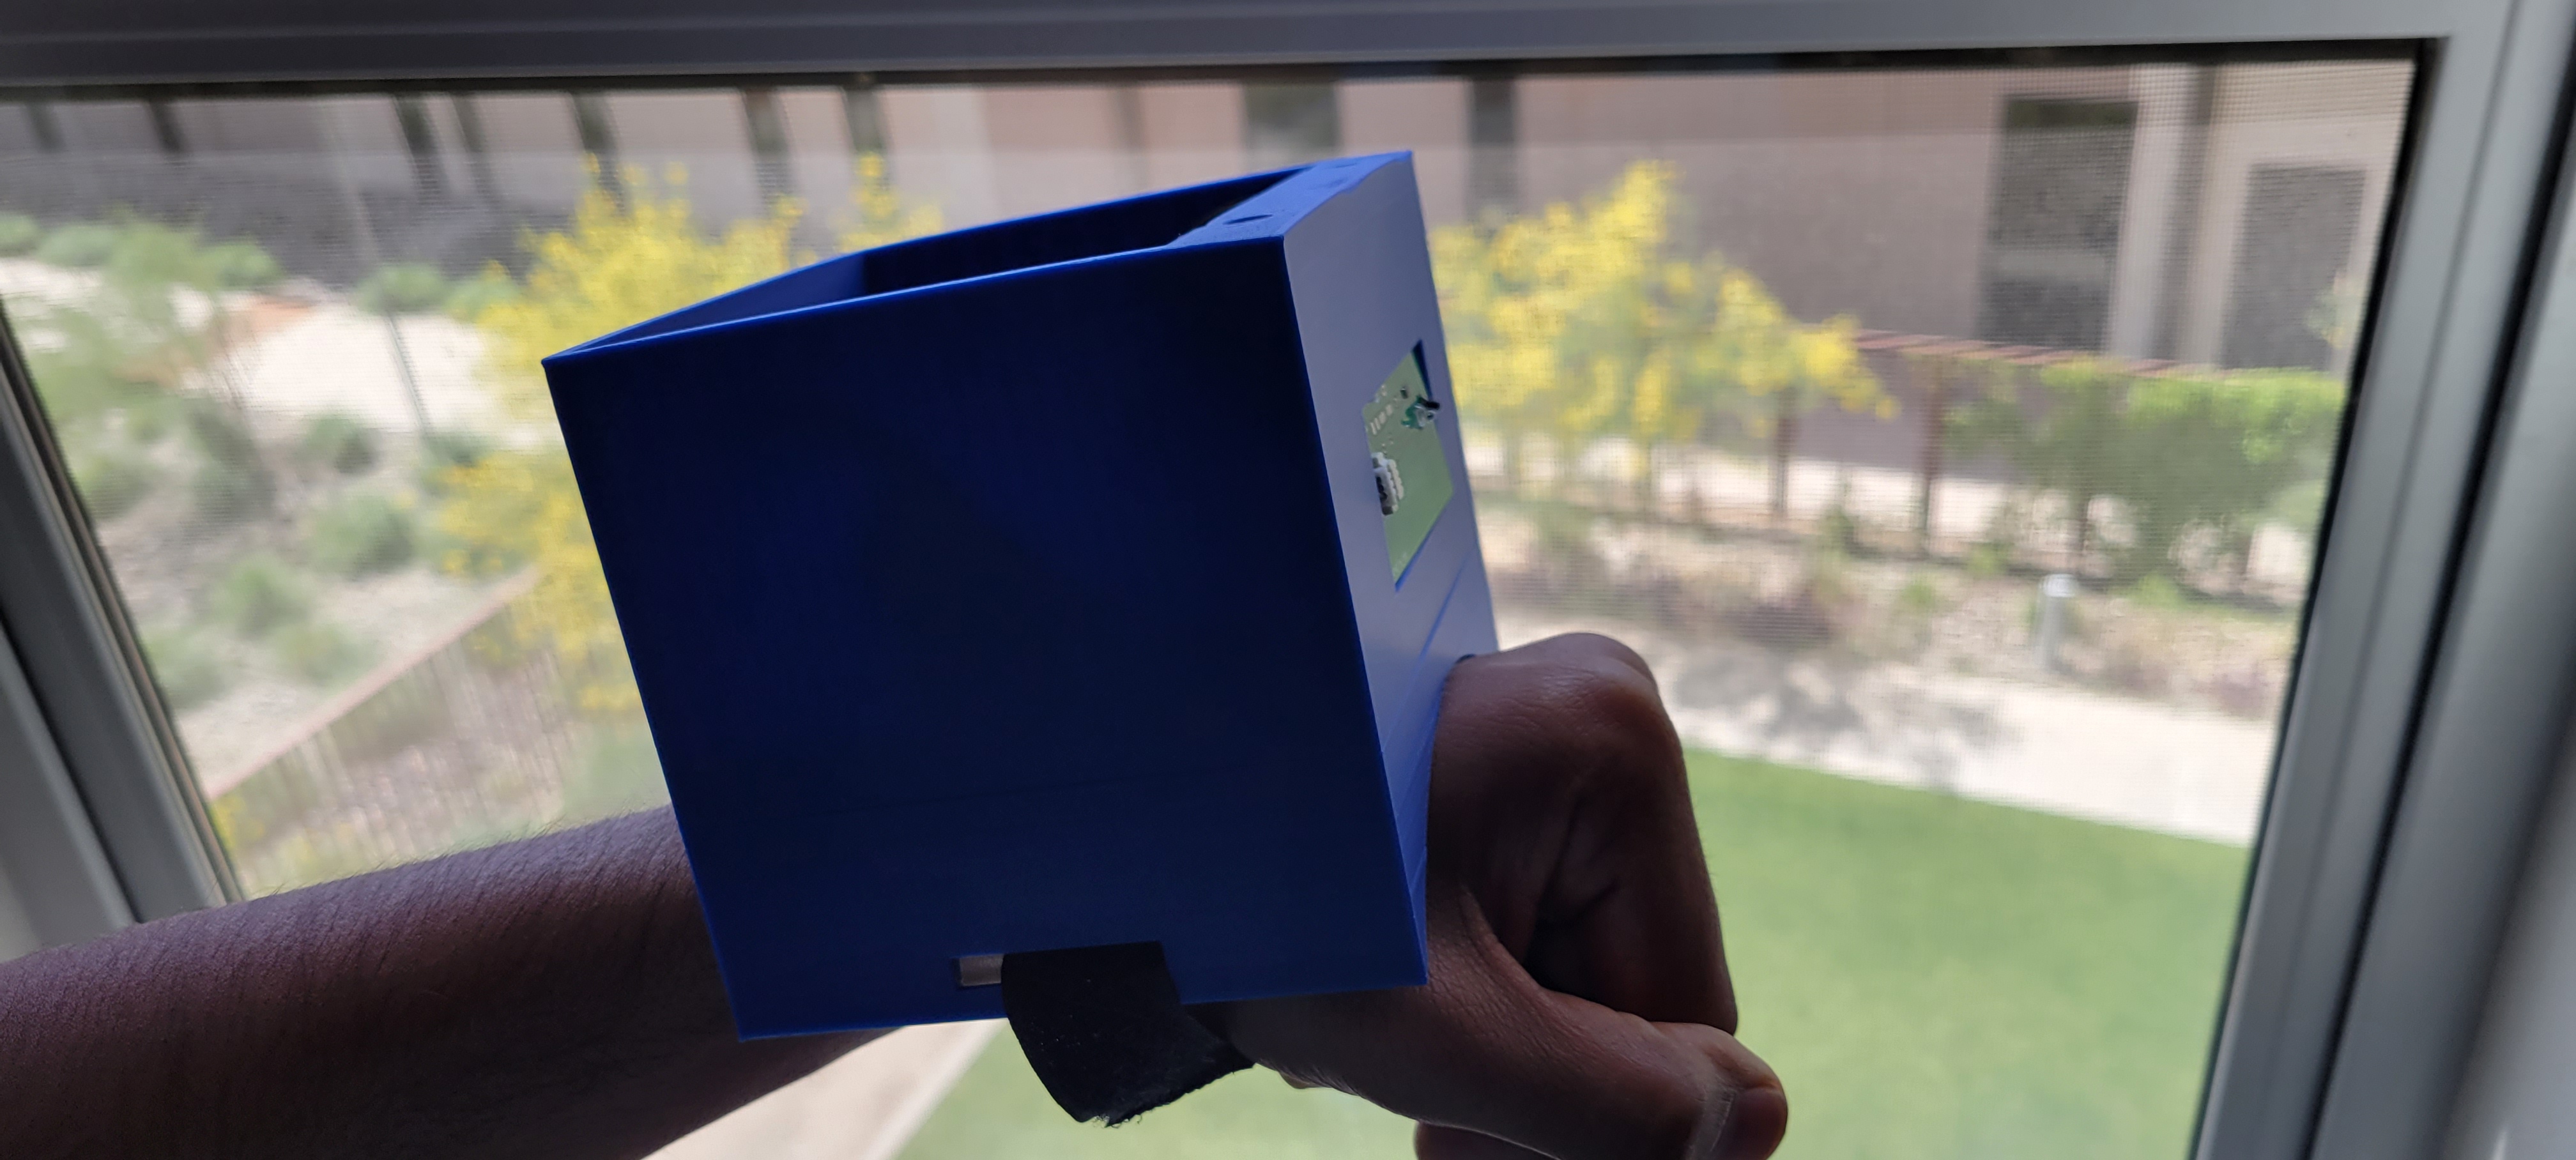
Developed a wearable embedded prototype that measures object distance and presents it on a compact display for users with impaired depth perception after stroke.
Jan 2022 - Apr 2022
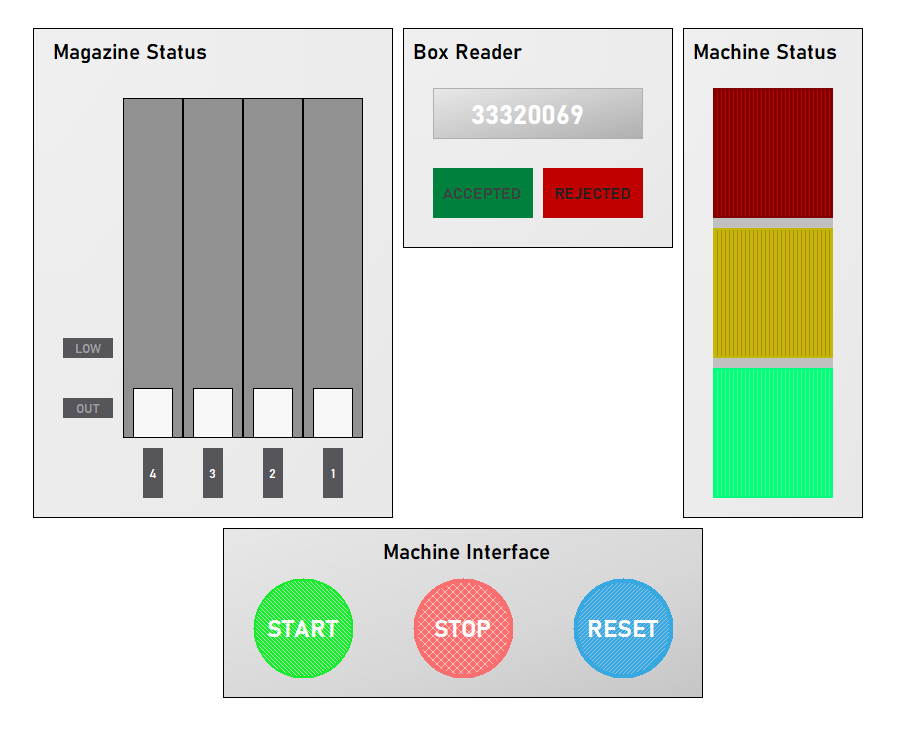
Automated an SMC HAS-200 workstation with Rockwell ladder logic, barcode-based sorting, pneumatic handling, and SCADA/HMI controls.
Aug 2021 – Dec 2021
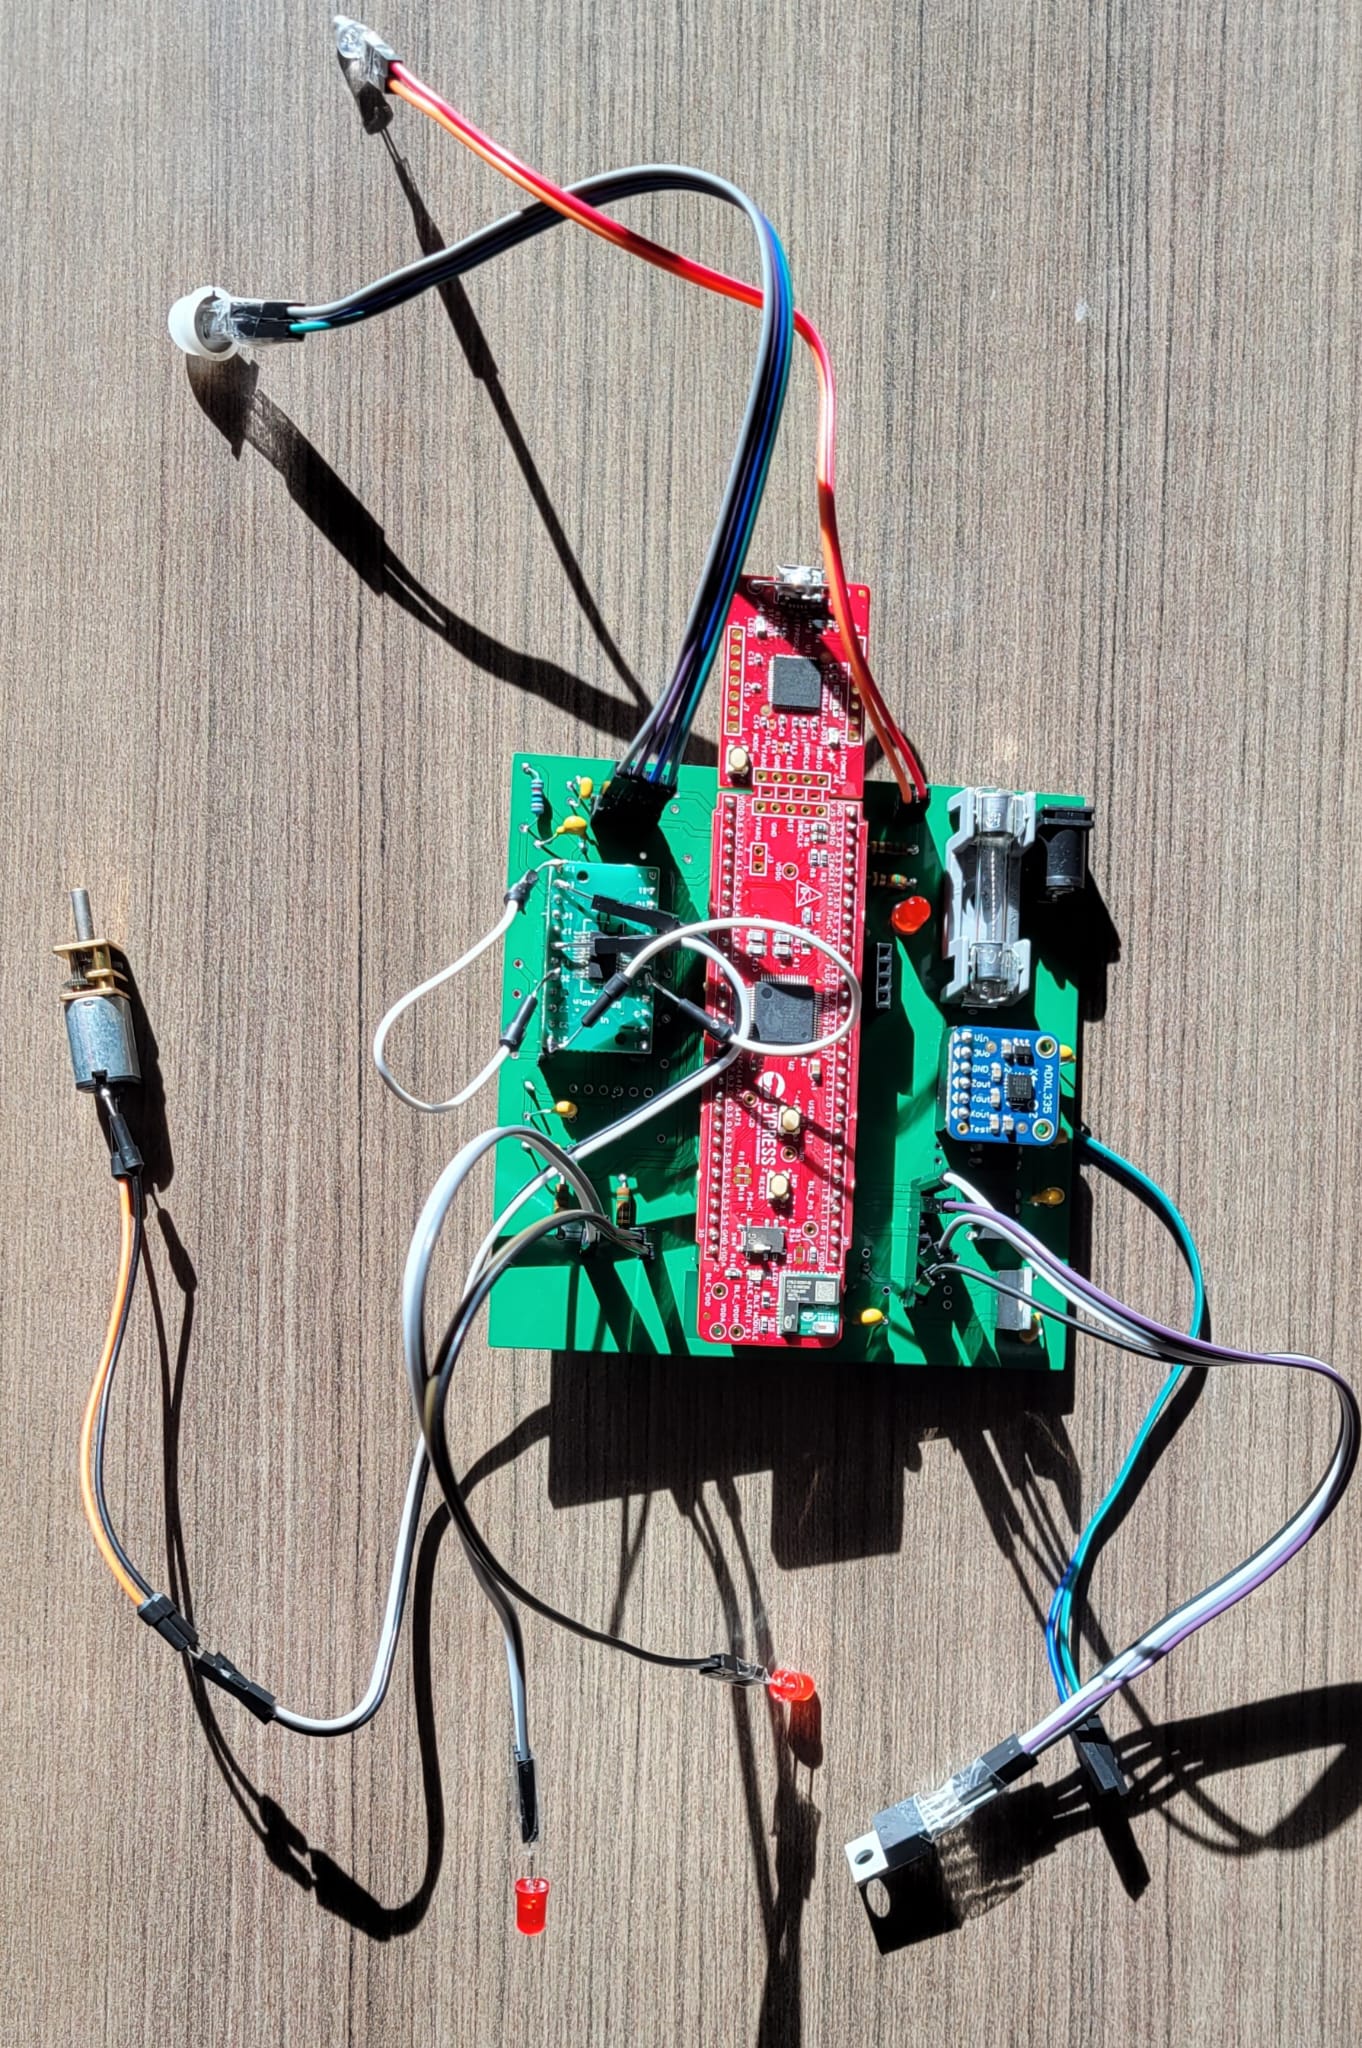
Designed and built a dual-mode holiday animatronic around a custom PSoC-based PCB, motion sensing, motor control, LEDs, and Bluetooth communication.
Aug 2021 – Dec 2021
Combined MATLAB kinematics with Bluetooth-based servo control to position a robotic arm and record repeatable motion sequences.