Robo_SIM: Manipulator Dynamics and Force-Control Package
Project Overview
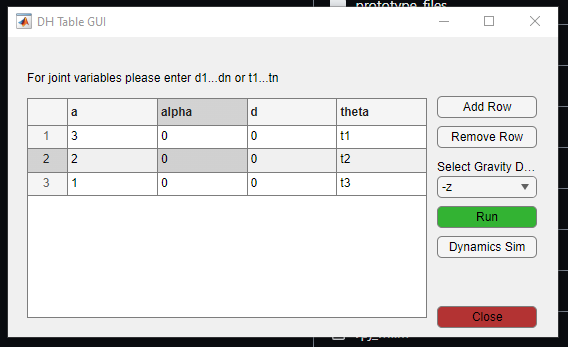
Robo_SIM is a MATLAB package for modeling and studying the dynamics and force control of serial robotic manipulators. A user supplies a Denavit–Hartenberg table, configures the simulation through a graphical interface, and analyzes the resulting joint and end-effector behavior.
Core Capabilities
Dynamics Simulation
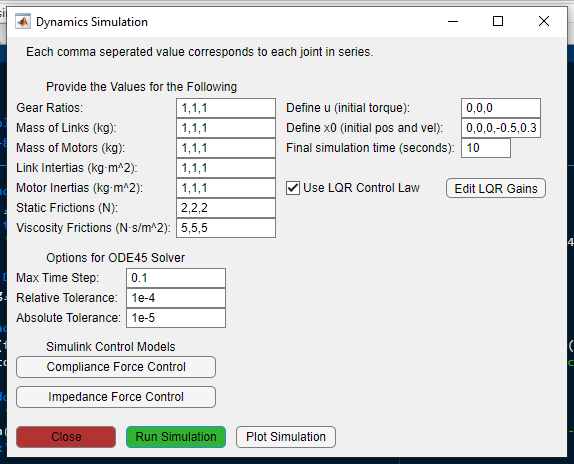
The package derives the manipulator equations of motion and simulates joint position, velocity, and acceleration for a selected mechanism and input trajectory. The plots expose both transient and steady-state behavior for model checking and controller evaluation.
Compliance Control
The compliance-control module combines proportional-derivative control with gravity compensation. It lets the end effector yield to external interaction forces while tracking a desired motion, and plots desired versus actual end-effector position together with contact force.
Impedance Control
The impedance controller uses inverse dynamics to shape the relationship between motion and environmental force. This provides a second indirect force-control strategy for comparing tracking behavior and interaction response.
Interactive GUI
The interface organizes DH-table entry, robot generation, simulation parameters, controller selection, and plotting so that users can explore different manipulators without rewriting the full analysis pipeline.
My Contributions
- Implemented and tested manipulator-dynamics calculations and simulation workflows.
- Developed force-control functionality for compliance and impedance experiments.
- Contributed to the interactive GUI and result visualization.
- Integrated user-defined robot geometry with the dynamics and control modules.
Outcome
The completed package provides a reusable educational environment for moving from kinematic description to dynamic simulation and force-control analysis. It supports rapid comparison of controller behavior while keeping the underlying robot model configurable.